Five Ways to Explore NASA’s Portfolio of Technologies with TechPort 4.0

Five Ways to Explore NASA’s Portfolio of Technologies with TechPort 4.0

3 min read

Preparations for Next Moonwalk Simulations Underway (and Underwater)

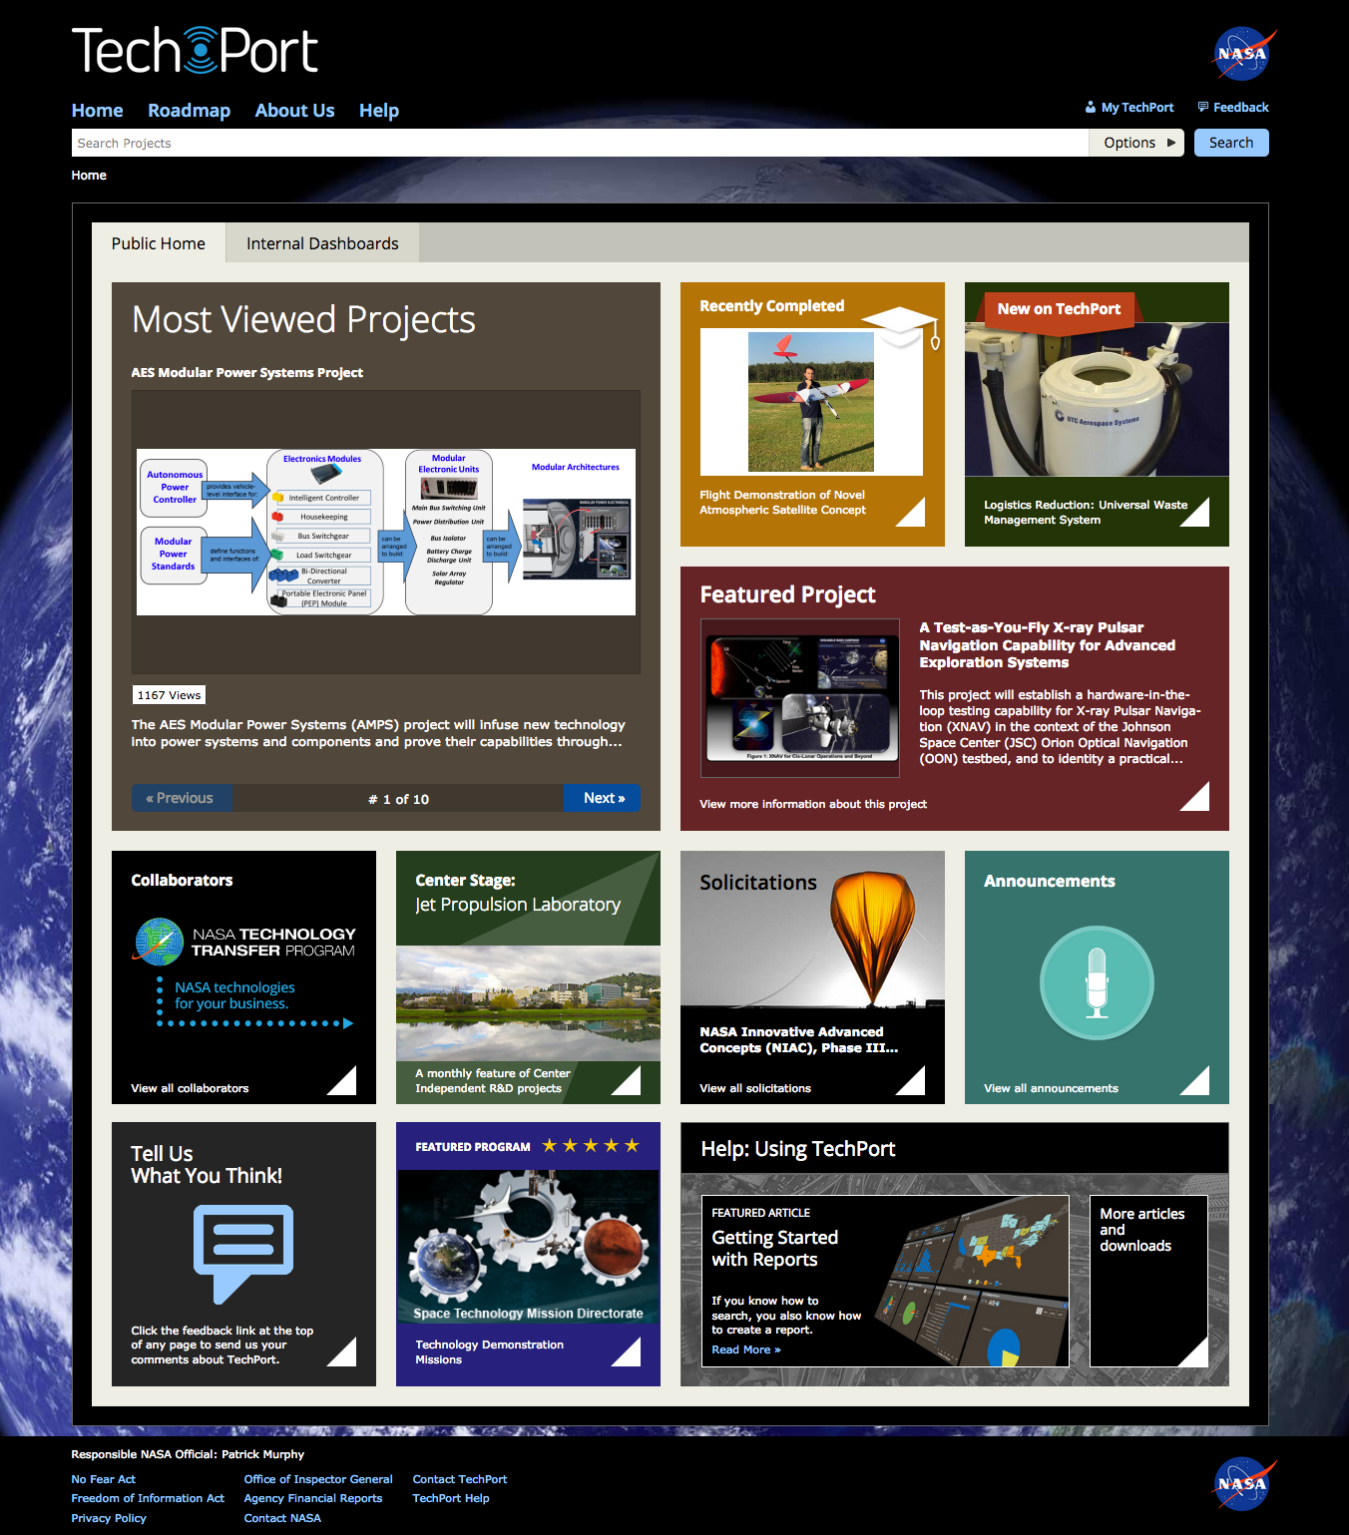
Have you ever wanted to find all your favorite NASA technology in one place? NASA stakeholders did, too! We listened to your feedback, brainstormed user-focused features, and created the most robust technology system to date.

NASA’s Space Technology Mission Directorate is excited to announce the release of TechPort version 4.0 – your gateway into our technology community. NASA tuned into feedback from the public, industry, academia, and our internal audiences to make significant updates to the TechPort system. From improvements in usability, customizability, and analysis views, users will now be able to search and explore NASA’s vast portfolio of technologies more easily than ever before.

Video introducing 4 new features of TechPort 4.0.
NASA

“When it comes to the ever-growing advancements in space technology, we need a system that encompasses a modernized look and feel coupled with a more intuitive interface,” said Alesyn Lowry, director for Strategic Planning & Integration for STMD at NASA Headquarters in Washington. “TechPort 4.0 offers just that. As the largest and most significant update to TechPort in the past five years, users will now be able to enjoy the most accessible, user-friendly, and all-encompassing version yet.” 

Check out the five features of TechPort 4.0 and how they can help you research NASA’s cutting-edge technology projects and partnerships: 

1. New and Improved Homepage 

Featuring a new look and feel, users are able to search NASA’s comprehensive system of vast technologies. Including over 18,000 current and historical NASA technologies, users will now have more access to knowledge about the agency’s technology development at the touch of their fingertips! The modernized look and feel lends itself to a more intuitive interface that upgrades technology search capabilities. 

2. Advanced Search 

One of the most exciting features of TechPort 4.0 is the new capability to search and filter on all fields associated with technologies. This advanced filtering feature will allow users to uncover the exact information they are seeking, creating a more accessible and swifter experience for users. 

3. New Grid View 

Expanding upon the previous view, TechPort 4.0 offers a new grid view that enables users to view even more project data all at once. This upgrade also allows a user to customize all of the fields visible in search results, tailor how the data is sorted, and filter on any visible field. This new view provides a familiar interface tailored to data analysis needs that require rapid review of multiple data facets simultaneously. 

Gridview of TechPort 4.0

4. NASA Technology Taxonomy Recommendation (T-Rex) 

NASA’s Technology Taxonomy provides a structure for technology classification spanning over 350 categories. The Taxonomy is featured in TechPort, and all technologies in the system align to at least one Taxonomy area, making it easy to view technologies of interest. Technologists from various fields, including academia and nonprofits, now have the opportunity to use the T-Rex tool to automatically classify their technology according to the NASA Taxonomy. Serving as a machine learning model, TechPort will offer more organization and an easier way for users to access relevant information. 

5. Funding Opportunities 

Now, users can get connected, too! If your TechPort research is inspiring you to think about solving an aerospace or technology challenge, TechPort 4.0 gives users easy access to relevant opportunities and information on how to apply. 

Launch into TechPort 4.0 to embark on your journey into our technology community. With the wide range of improvements in accessibility and customizability, explore NASA technologies like never before! 

Gabrielle Thaw
Powered by WPeMatico

Get The Details…
Loura Hall

Nargess Memarsadeghi, Computer Engineer for the Cosmos

Nargess Memarsadeghi, Computer Engineer for the Cosmos

5 min read

Preparations for Next Moonwalk Simulations Underway (and Underwater)

When it comes to building spaceflight missions, the software is at least as important as the hardware. For computer engineer Nargess Memarsadeghi, having a hand in the programming is like getting to go along for the ride.

Name: Nargess Memarsadeghi
Title: Associate Branch Head, Software Systems Engineering Branch
Formal Job Classification: Supervisory Computer Engineer
Organization: Software Systems Engineering Branch, Software Engineering Division, Engineering Directorate (Code 581)

Nargess Memarsadeghi, wearing a black short sleeve shirt, smiles are the camera in front of a window looking into Goddard's large clean room with spacecraft equipment in the background.
Nargess Memarsadeghi is the associate branch head of the Software Systems Engineering branch at NASA’s Goddard Space Flight Center in Greenbelt, Md.
Courtesy of Nargess Memarsadeghi

What do you do and what is most interesting about your role here at Goddard?

As associate branch head for the Software Systems Engineering Branch, I spend half of my time supporting the branch head on internal functions, different planning activities, and supervising our employees who are senior software systems engineers and often team leads themselves.

For the other half of my time, I work on a technical project. Currently, I am supporting the Human Landing Systems (HLS) project. I am a member of NASA HLS Software Insight Team working with NASA’s Marshall Space Flight Center in Huntsville, Alabama, and Johnson Space Center in Houston, and industry partners SpaceX and Blue Origin to meet software requirements and milestones, and to ensure the Artemis campaign succeeds in taking astronauts to the Moon.

I enjoy learning about various NASA missions and being part of them either by supporting our branch employees who work on these missions or by being a project team member and making technical contributions directly.

Why did you become a software engineer?

I always loved math and sciences. Software engineering seemed like a good and practical way to apply math to different scientific and engineering applications.

What is your educational background?

I got my bachelor’s (2001), master’s (2004), and doctorate (2007) degrees in computer science from the University of Maryland at College Park.

How did you come to Goddard?

I joined Goddard in 2001 right after college. The university had a recruitment event at its career center. I signed up for an interview with NASA, which went well.  I then got an invitation for an onsite interview, and then an offer to join Goddard as a computer engineer.

What is your supervisory style?

I have been supervising on average 10 employees. We have tag-ups every two weeks to learn about their work and see if they have any issues or need anything from management. We keep in constant communication which goes both ways. I have an open-door policy. I try to match an employee’s interests and expertise to their work. I am willing to hear their concerns and address them to the best of my ability or putting them in contact with those who can. I enjoy learning about their work and celebrating the achievements.

What are some of the most exciting projects and missions that the Software Systems Engineering Branch is involved with?

We provide end-to-end software systems engineering support to many high-impact missions, like the upcoming flagship astrophysics Roman Space Telescope mission. We support Roman’s software systems, as well as its testing and assembly with one of our software products, the Goddard Dynamic Simulator.

Our team also supports a variety of Earth science missions, such as the Joint Polar Satellite Systems (JPSS), GOES-R, and GOES-U, all of which NASA supports on behalf of the National Oceanic and Atmospheric Administration (NOAA). We also develop and manage different ground segment software systems for different missions including PACE, TSIS-II, and others.

What are some of your career highlights so far?

One was being part of the James Webb Space Telescope team and working on stability testing of microshutters. Webb is a huge, multinational observatory  making many scientific discoveries.

Another is being part of the Dawn mission’s satellite working group searching for moons of the asteroid Vesta and dwarf planet Ceres. I worked on this from prelaunch through launch and operations. We were some of the first to see the scientific images soon after being downlinked. It felt like going on a ride with the spacecraft itself.

I would add my more recent work on the Roman Space Telescope.

In general, I really enjoyed working on various missions during their different stages of their life cycle. I got to see the whole picture of how software is used for missions, from technology development to post-launch.

What advice do you give your graduate students and interns as a mentor?

I emphasize that they also need to work on their communication skills, leadership skills, and team building. I tell them to focus not just on their technical skills but also on their interpersonal skills both written and oral. NASA has a lot of collaborative projects and being able to effectively communicate across different levels is crucial for mission success.

Whom do you wish to thank?

I would like to thank my family for their support. I would also like to thank my past teachers and mentors who made a big difference in me and positively impacted my life.

What do you do to relax?

I like going for long walks, spending time with family and friends, and doing activities with my son including attending his piano recitals.

Who is your favorite author?

As a young reader, I enjoyed reading Jules Verne. I also enjoy reading poetry. My favorites are Robert Frost, Emily Dickinson, and Persian poets Sohrab Sepehri and Saadi Shirazi.

What motto do you live by?

Be the change you want to see in the world.

By Elizabeth M. Jarrell
NASA’s Goddard Space Flight Center, Greenbelt, Md.

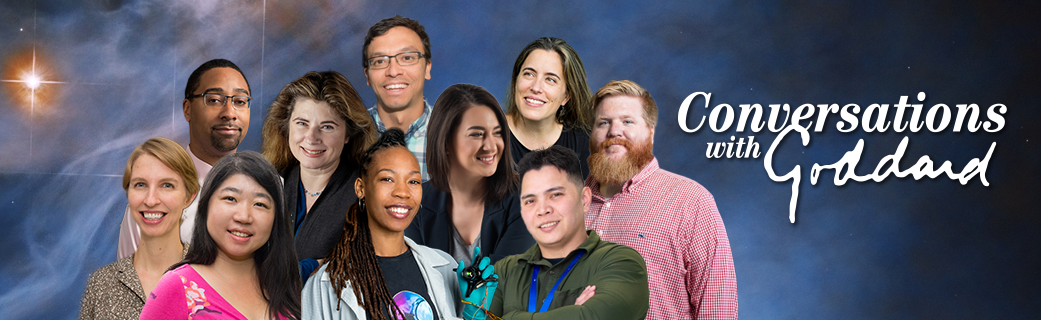
A banner graphic with a group of people smiling and the text "Conversations with Goddard" on the right. The people represent many genders, ethnicities, and ages, and all pose in front of a soft blue background image of space and stars.

Conversations With Goddard is a collection of Q&A profiles highlighting the breadth and depth of NASA’s Goddard Space Flight Center’s talented and diverse workforce. The Conversations have been published twice a month on average since May 2011. Read past editions on Goddard’s “Our People” webpage.

Share

Details

Last Updated

Dec 19, 2024

Powered by WPeMatico

Get The Details…
Jamie Adkins

Statistical Analysis Using Random Forest Algorithm Provides Key Insights into Parachute Energy Modulator System

Statistical Analysis Using Random Forest Algorithm Provides Key Insights into Parachute Energy Modulator System

Download PDF: Statistical Analysis Using Random Forest Algorithm Provides Key Insights into Parachute Energy Modulator System

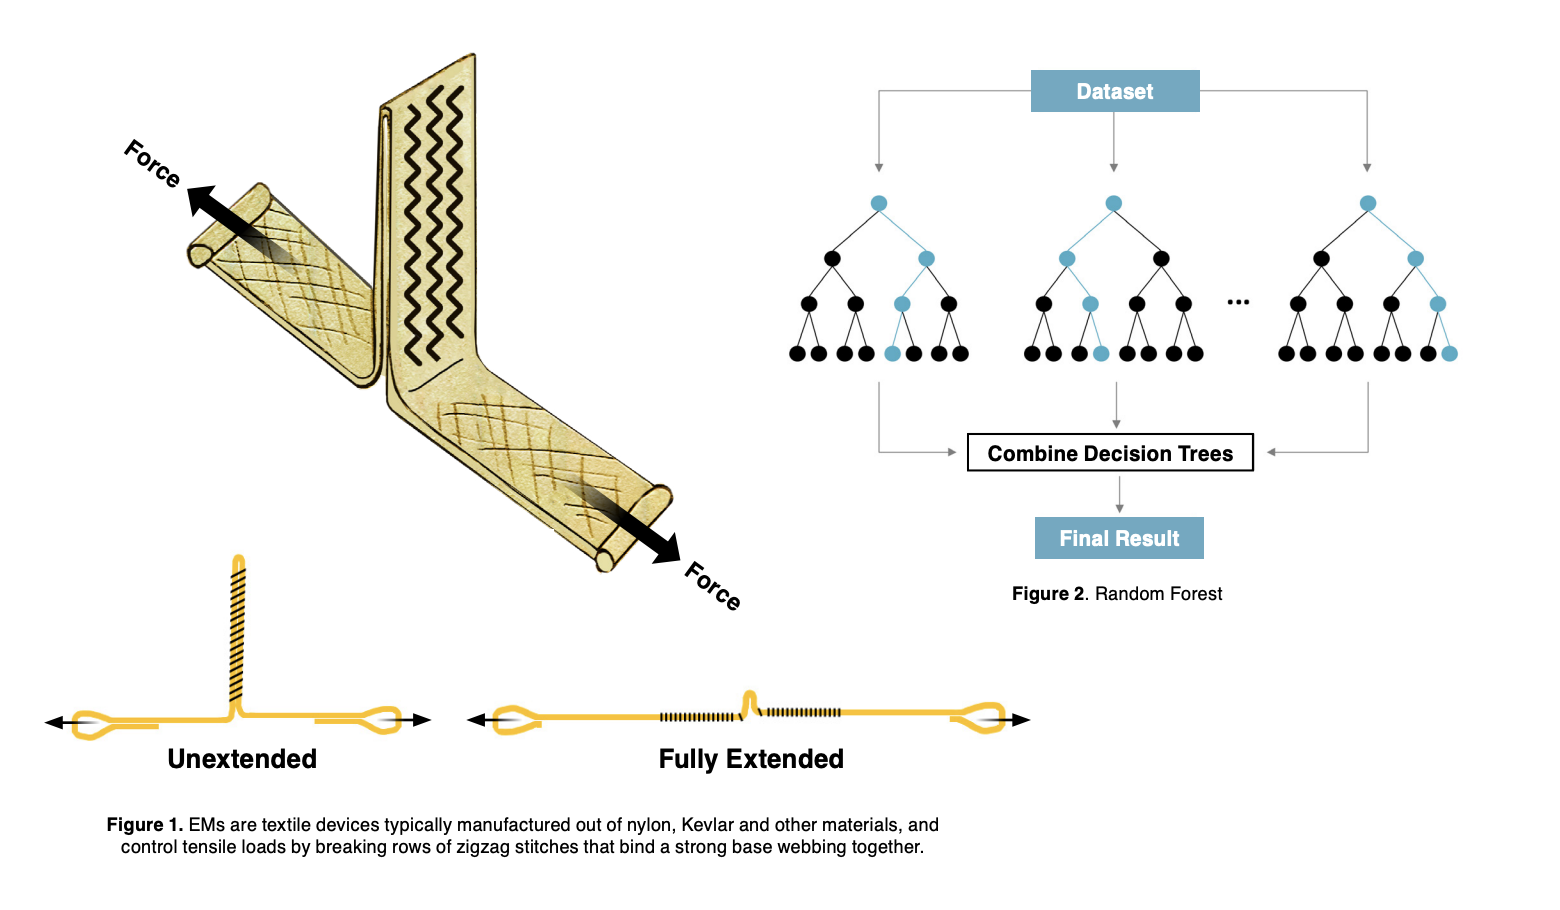
Energy modulators (EM), also known as energy absorbers, are safety-critical components that are used to control shocks and impulses in a load path. EMs are textile devices typically manufactured out of nylon, Kevlar® and other materials, and control loads by breaking rows of stitches that bind a strong base webbing together as shown in Figure 1. A familiar EM application is a fall-protection harness used by workers to prevent injury from shock loads when the harness arrests a fall. EMs are also widely used in parachute systems to control shock loads experienced during the various stages of parachute system deployment.

Random forest is an innovative algorithm for data classification used in statistics and machine learning. It is an easy to use and highly flexible ensemble learning method. The random forest algorithm is capable of modeling both categorical and continuous data and can handle large datasets, making it applicable in many situations. It also makes it easy to evaluate the relative importance of variables and maintains accuracy even when a dataset has missing values.

IT NESC - Figure 1. EMs are textile devices typically manufactured out of nylon, Kevlar and other materials, and control tensile loads by breaking rows of zigzag stitches that bind a strong base webbing together.

Random forests model the relationship between a response variable and a set of predictor or independent variables by creating a collection of decision trees. Each decision tree is built from a random sample of the data. The individual trees are then combined through methods such as averaging or voting to determine the final prediction (Figure 2). A decision tree is a non-parametric supervised learning algorithm that partitions the data using a series of branching binary decisions. Decision trees inherently identify key features of the data and provide a ranking of the contribution of each feature based on when it becomes relevant. This capability can be used to determine the relative importance of the input variables (Figure 3). Decision trees are useful for exploring relationships but can have poor accuracy unless they are combined into random forests or other tree-based models.

The performance of a random forest can be evaluated using out-of-bag error and cross-validation techniques. Random forests often use random sampling with replacement from the original dataset to create each decision tree. This is also known as bootstrap sampling and forms a bootstrap forest. The data included in the bootstrap sample are referred to as in-the-bag, while the data not selected are out-of-bag. Since the out-of-bag data were not used to generate the decision tree, they can be used as an internal measure of the accuracy of the model. Cross-validation can be used to assess how well the results of a random forest model will generalize to an independent dataset. In this approach, the data are split into a training dataset used to generate the decision trees and build the model and a validation dataset used to evaluate the model’s performance. Evaluating the model on the independent validation dataset provides an estimate of how accurately the model will perform in practice and helps avoid problems such as overfitting or sampling bias. A good model performs well on
both the training data and the validation data.

The complex nature of the EM system made it difficult for the team to identify how various parameters influenced EM behavior. A bootstrap forest analysis was applied to the test dataset and was able to identify five key variables associated with higher probability of damage and/or anomalous behavior. The identified key variables provided a basis for further testing and redesign of the EM system. These results also provided essential insight to the investigation and aided in development of flight rationale for future use cases.

IT NESC- figure-3--example-of-decision-tree-and-variable-rankings-from-bootstrap-forest

For information, contact Dr. Sara R. Wilson. sara.r.wilson@nasa.gov

Powered by WPeMatico

Get The Details…
Meagan Chappell

Contact Dynamics Predictions Utilizing theNESC Parameterless Contact Model

Contact Dynamics Predictions Utilizing theNESC Parameterless Contact Model

Download PDF: Contact Dynamics Predictions Utilizing theNESC Parameterless Contact Model

Modeling the capture of the Mars Sample Return (MSR) Orbiting Sample (OS) involves understanding complex dynamic behavior, which includes the OS making contact against the interior of the capture enclosure. The MSR Program required numerical verification of the contact dynamics’ predictions produced using their commercial software tools. This commercial software used “free” parameters to set up the contact modeling. Free parameters (also known as free variables) are not based on contact physics. The commercial contact model used by MSR
required seven free parameters including a Hertzian contact stiffness, surface penetration, stiffening exponent, penetration velocity, contact damping, maximum penetration depth for the contact damping value, and a smoothing function. An example of a parameter that is not free is coefficient of friction, which is a physics-based parameter. Consider the free parameter, contact stiffness. Contact stiffness is already present in the finite element model’s (FEM) stiffness matrix where the bodies come into contact, and surface penetration is disallowed in a physically realizable contact model, as FEM meshes should not penetrate one another during contact (i.e., the zero-contact limit penetration constraint condition).

As such, with each set of selected free parameters generating a different contact force signature, additional numerical verification is required to guide setting these parameters. Contact modeling is nonlinear. This means that the stiffness matrices of contacting bodies are continuously updated as the bodies come into contact, potentially recontact (due to vibrations), and disengage. The modal properties of contacting bodies continuously change with state transitions (e.g., stick-to-slip). Some contact models have been proposed and incorporated in commercial finite element analysis solvers, and most involve static loading. A relatively smaller number involve dynamics, which has historically proven challenging.

IT NESC f1-contact-force-and-relative-displacement-

In 2005, NASA conducted a study testing several commercial contact solvers in predicting contact forces in transient dynamic environments. This was necessitated by the Space Shuttle Program (SSP)—after the February 2003 Columbia accident— deciding to include contact dynamics in the Space Shuttle transient coupled loads analysis (CLA) to capture the impact of contact nonlinearities. This rendered the entire CLA nonlinear. The study found major difficulties executing nonlinear CLAs in commercial software. A nonlinear solver developed by the NESC and Applied Structural Dynamics (ASD) that was able to produce physically realizable results was numerically verified by NASA and later experimentally validated as well. This nonlinear solver was subsequently utilized to execute all NASA SSP CLAs (i.e., crewed space flights) from 2005 to the final flight in 2011, as well as currently supporting the SLS Program.

The objective of the MSR contact verification work was to provide data that could be used by the MSR team to help define the free parameters listed above for the commercial tool contact model. The NESC/ASD solver was used to model contact between simple cantilever and free beams, deriving contact forces and relative displacements. These resulting data can be used to determine parameter values for more complex structures. Two of the modeled configurations, one for axial contact (Figure 1) and the other for stick/friction (Figure 2), and sample results from the NESC nonlinear dynamic analyses are presented in Figures 1 and 2.

IT NESC contact-force-and-relative-displacement-

For information, contact:
Dr. Dexter Johnson dexter.johnson@nasa.gov
Dr. Arya Majed arya.majed@nasa.gov

Powered by WPeMatico

Get The Details…
Meagan Chappell

NASA Names Carlos Garcia-Galan as Gateway Program Deputy Manager

NASA Names Carlos Garcia-Galan as Gateway Program Deputy Manager

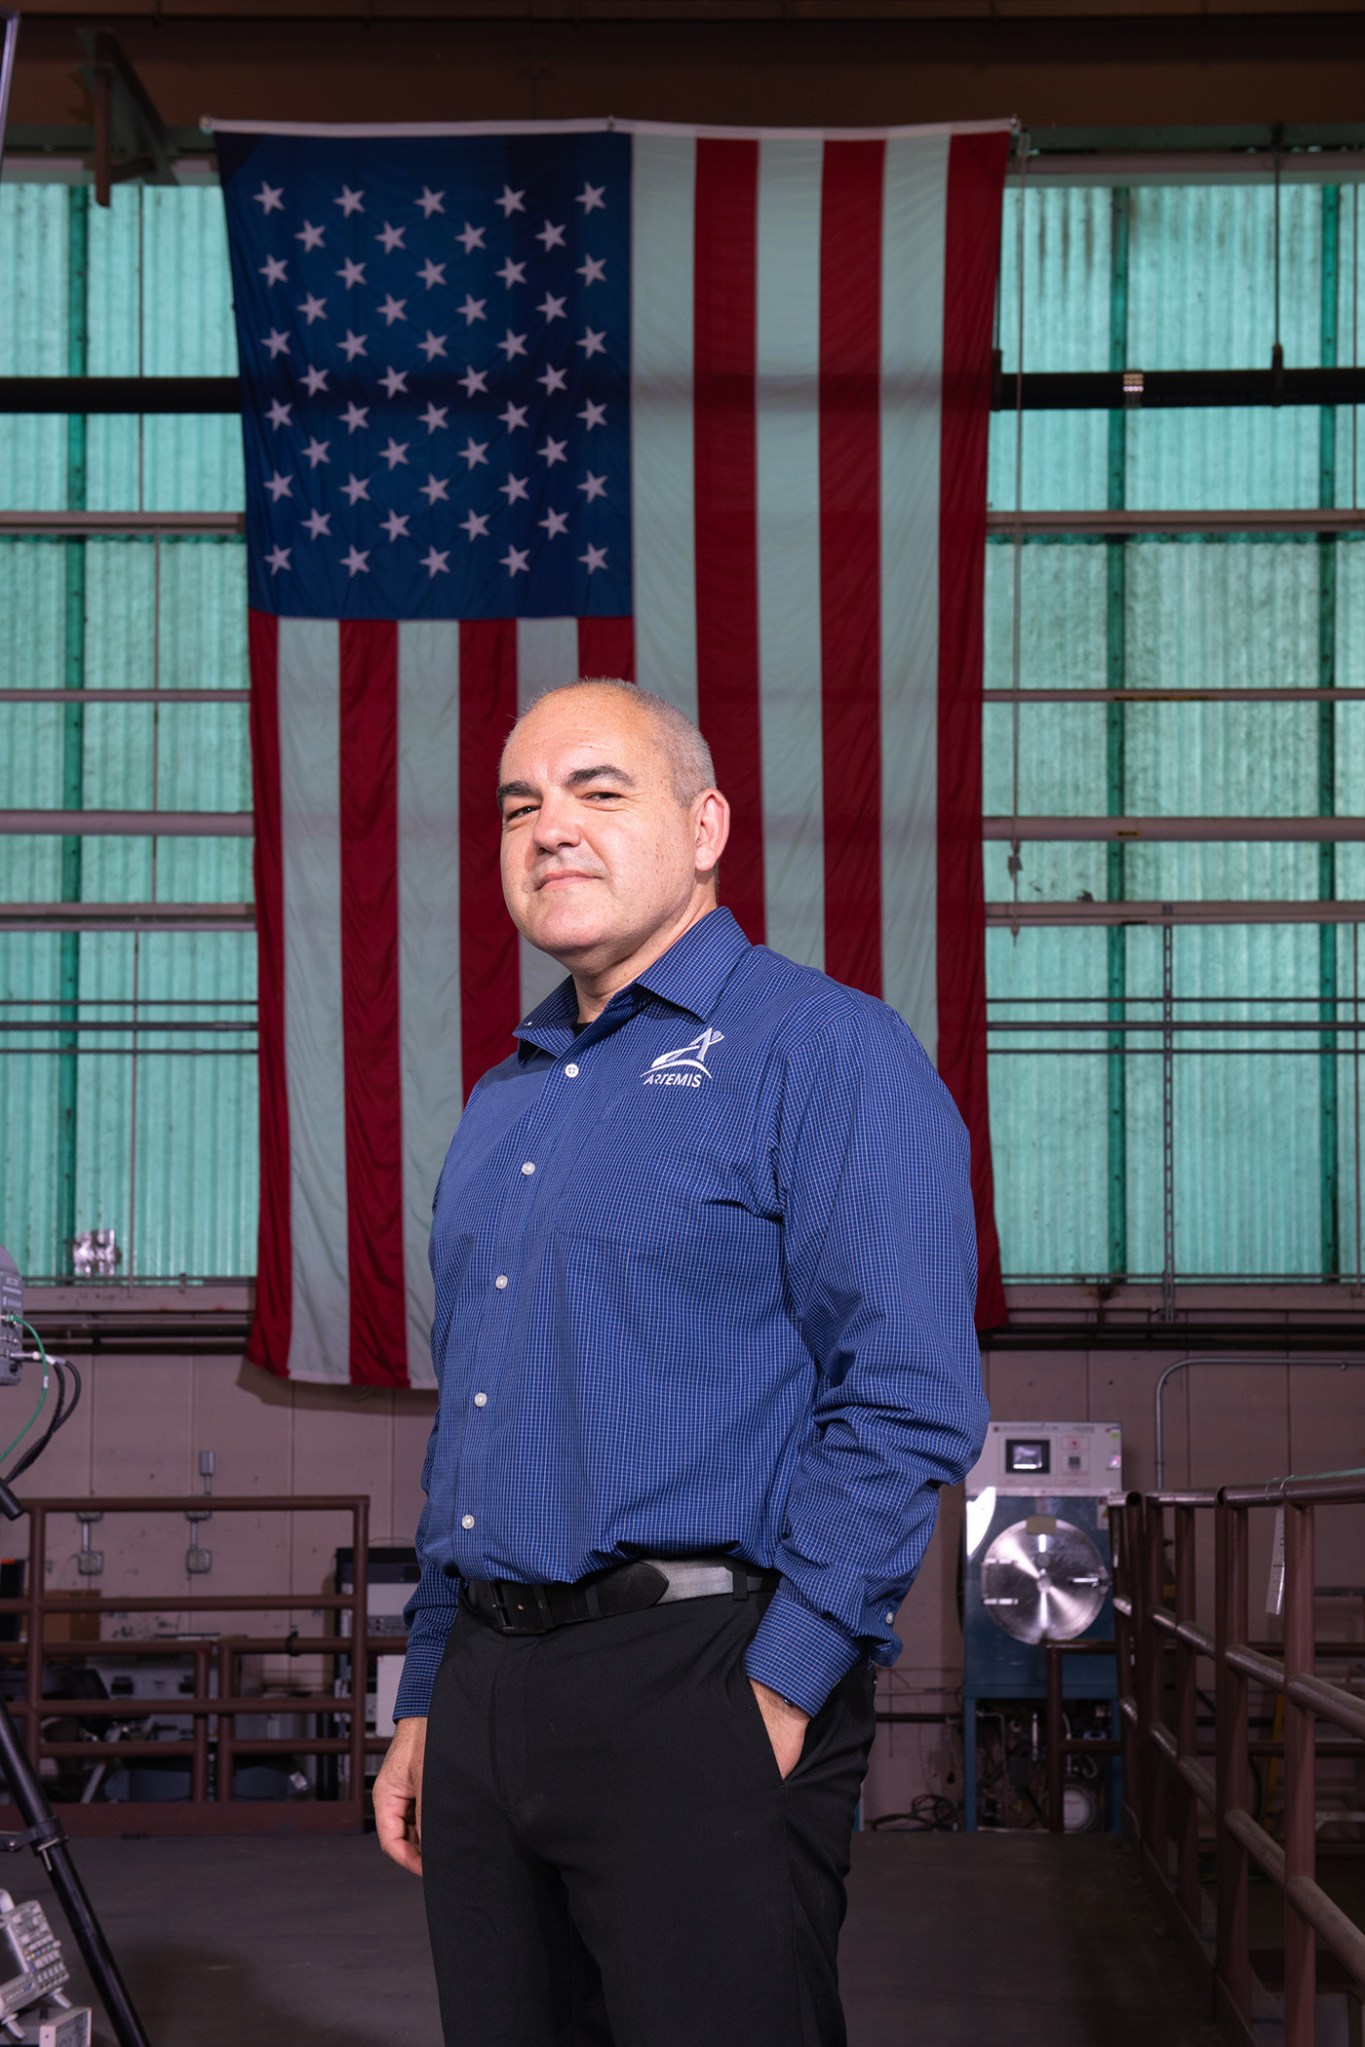
Carlos Garcia-Galan poses in front of the American flag in the Electric Propulsion and Power Laboratory at NASA’s Glenn Research Center. He has a serious expression is wearing a blue long-sleeve shirt with the Artemis program logo and black pants.
Official portrait of Carlos Garcia-Galan, deputy manager for the Gateway Program.
NASA/Bridget Caswell

NASA has selected Carlos Garcia-Galan as deputy manager for the Gateway Program. Garcia-Galan previously served as manager of the Orion Program’s European Service Module Integration Office at Glenn Research Center.

“I am tremendously excited to take on this new role and help lead development of humanity’s first outpost in deep space,” Garcia-Galan said. “I’m honored to join a top-class Gateway team around the world, as the first elements of the complex move toward completion.”

Garcia-Galan brings more than 27 years of human spaceflight experience to the role. A native of Malaga, Spain, his career includes supporting assembly of the International Space Station as a flight controller in Houston and Korolev, Russia, during multiple Space Shuttle-International Space Station assembly flights. He joined the Orion program in 2010, serving in a variety of key technical and management roles, including management of integrated spacecraft design and performance, mission analysis, cross-program integration, and launch and flight operations support.

“Carlos is an outstanding manager and engineer, and I am extremely pleased to announce his selection for this position,” said Vanessa Wyche, director of NASA’s Johnson Space Center. “His wealth of experience in human spaceflight, international partnerships, and the development and operations of deep-space spacecraft will be a huge asset to Gateway.”

While with the Orion Program, Garcia-Galan had a key role preparing the Orion team for the Artemis I mission by establishing the Orion Mission Evaluation Room (MER) concept of operations and leading the team through the Artemis I flight preparations until he transitioned into his role managing ESM integration. He later served as one of the Artemis I MER Leads supporting real-time flight operations during the successful Artemis I mission.

“Carlos brings a tremendous technical background and extensive leadership experience that will greatly benefit our program, augmenting our strong team as we progress towards deploying the lunar Gateway,” said Gateway Program Manager Jon Olansen.

Throughout his career, Garcia-Galan has been recognized for his achievements, including receiving, the Honeywell Space Systems Engineer of the Year (Houston) award, the NASA Silver Achievement Medal, the Exceptional Achievement Medal, the Johnson Space Center Director’s Commendation, the Orion Program Manager’s Commendation, and the Silver Snoopy Award.


Learn More About Gateway

@NASAGateway

@NASA_Gateway

@nasaartemis

Powered by WPeMatico

Get The Details…
Sumer Loggins