APOD: 2026 September 28 – Cosmic Latte: The Average Color of the Universe

APOD: 2026 September 28 – Cosmic Latte: The Average Color of the Universe

APOD

Astronomy Picture of the Day

Discover the cosmos! Each day a different image or photograph of our fascinating universe is featured, along with a brief explanation written by a professional astronomer.

A single color covers the image: that similar to a latte cup of coffee. It is noted in text that apod.nasa.gov is moving to science.nasa.gov/apod.A single color covers the image: that similar to a latte cup of coffee.

Cosmic Latte: The Average Color of the Universe

Explanation: What color is the universe? More precisely, if the entire sky were smeared out, what color would the final mix be? This whimsical question came up when trying to determine what stars are commonplace in nearby galaxies. The answer, depicted here, is a conditionally perceived shade of beige. In computer parlance: #FFF8E7. To determine this, astronomers computationally averaged the light emitted by one of the larger samples of galaxies analyzed: the 200,000 galaxies of the 2dF Galaxy Redshift Survey. The resulting cosmic spectrum has some emission in all parts of the electromagnetic spectrum, but a single perceived composite color. This color has become much less blue over the past 10 billion years, indicating that redder stars are becoming more prevalent. In a contest to better name the color, notable entries included skyvory, univeige, and the winner: cosmic latte.

APOD’s email for image submissions has changed. Please see: APOD Submissions
Tomorrow: APOD’s main NASA site is moving: From apod.nasa.gov to science.nasa.gov/apod
Tomorrow’s picture: sky swirl

Date: September 28, 2026
Color Credit: Karl Glazebrook & Ivan Baldry (JHU)
Authors & editors: Robert Nemiroff, Jerry Bonnell, Cecilia Chirenti, Keighley Rockcliffe
A service of: ASD at NASA / GSFC,
NASA Science Activation & Michigan Tech. U.

Powered by WPeMatico

Get The Details…

Reliable Robots: Meet Johnson’s Dexterous Robotics Team

Reliable Robots: Meet Johnson’s Dexterous Robotics Team

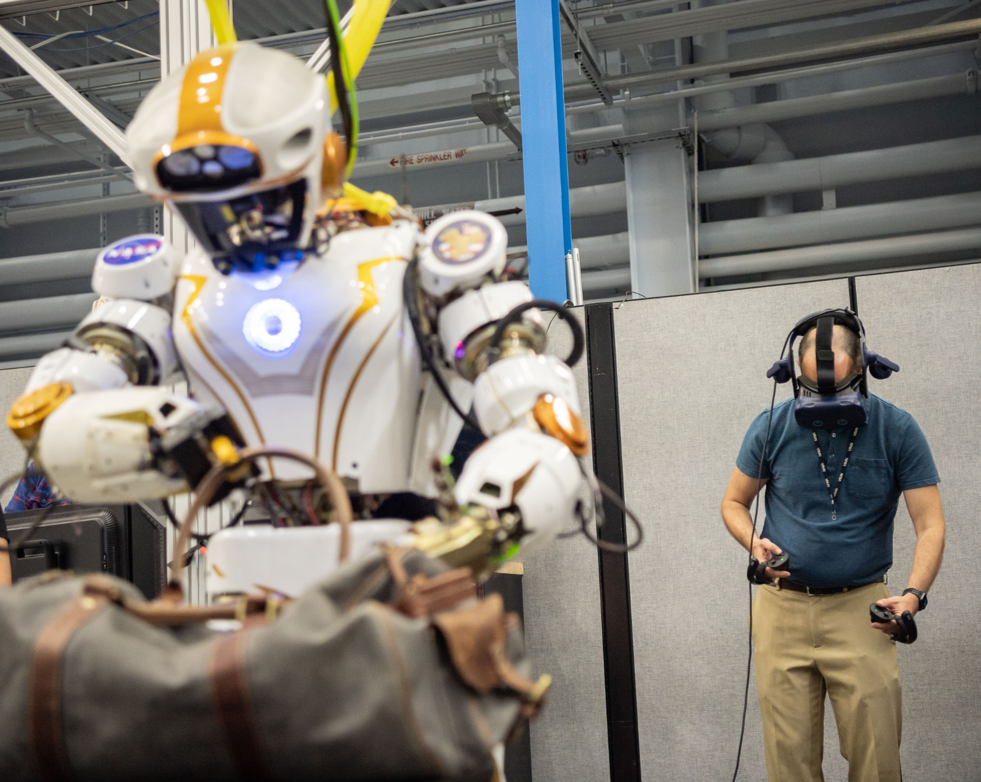
A humanoid robot stands in the foreground, lifting a duffel bag. A man in the background wears a VR headset and holds hand controllers, apparently controlling the robot's movements.
Dexterous Robotics Team lead Shaun Azimi conducts a demonstration with NASA’s Valkyrie humanoid robot.
NASA

The idea of humans and robots working side-by-side in space was once the stuff of science fiction, but with NASA launching increasingly complex missions deeper into space, human-robot collaboration could become reality.

Advanced robotic systems are critical for human spaceflight because they can enhance a crew’s performance and productivity while reducing risk and expanding the capabilities for space exploration. The Dexterous Robotics Team at NASA’s Johnson Space Center in Houston plays a key role in developing robotic hardware and software to support NASA’s bold vision for the future, with a focus on robots that can complete tasks humans do with their hands. 

“Our team is not trying to replace human explorers with robots but instead make human exploration safer and more sustainable by developing highly capable, reliable, and trustworthy robots to work in extreme environments,” said Shaun Azimi, Dexterous Robotics Team lead. “If we can send more capable robots, we can reduce the risk and make people more effective in doing the things that people do best.”

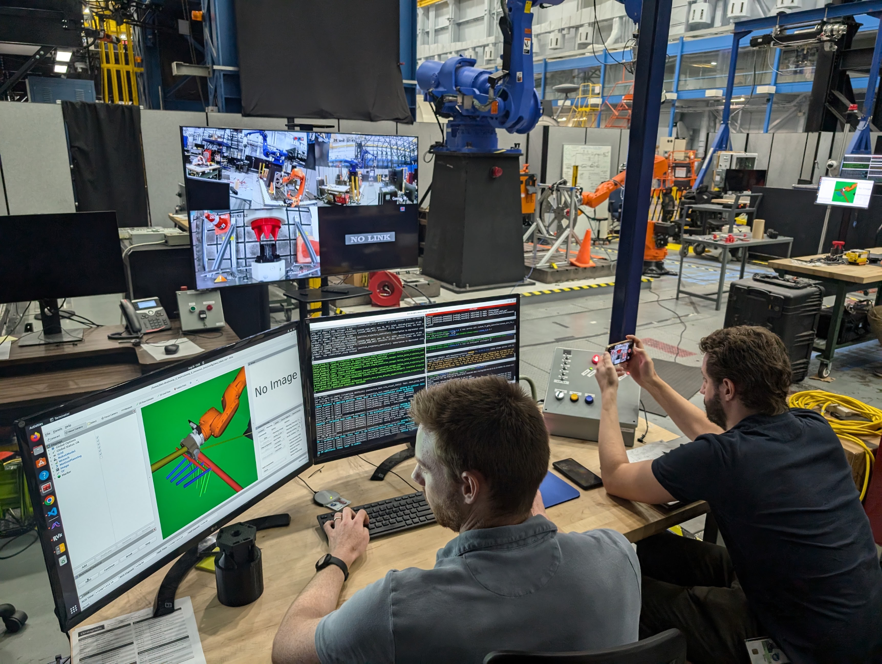
Two men sit at a wooden table with two large computer monitors displaying data and imagery from a robotic arm test. They sit in a large, open facility with additional computer monitors and robotic equipment in the background.
Dexterous Robotics Team members Nathan Dunkelberger (left) and Connor Rainen test the use of a robotic arm.
NASA

The 16-member team is part of NASA’s Robotic System Technology Branch, which also develops mobility systems like unmanned planetary rovers. Azimi is one of several engineers who work on both dexterity and mobility projects. There is also crossover within the Dexterous Robotics Team. While the group is generally organized into two subgroups, mechatronics and software, most team members have experience in electronics or mechanics as well as writing software for simulations or analyses.

Much of that experience was gained by working on two well-known humanoid robots – the Robonaut 2, which participated in robotics technology demonstrations aboard the International Space Station for seven years, and Valkyrie, NASA’s first bipedal humanoid robot. Many of the employees who worked on those projects now make up the Dexterous Robotics Team and continue to build upon the robots’ legacy.

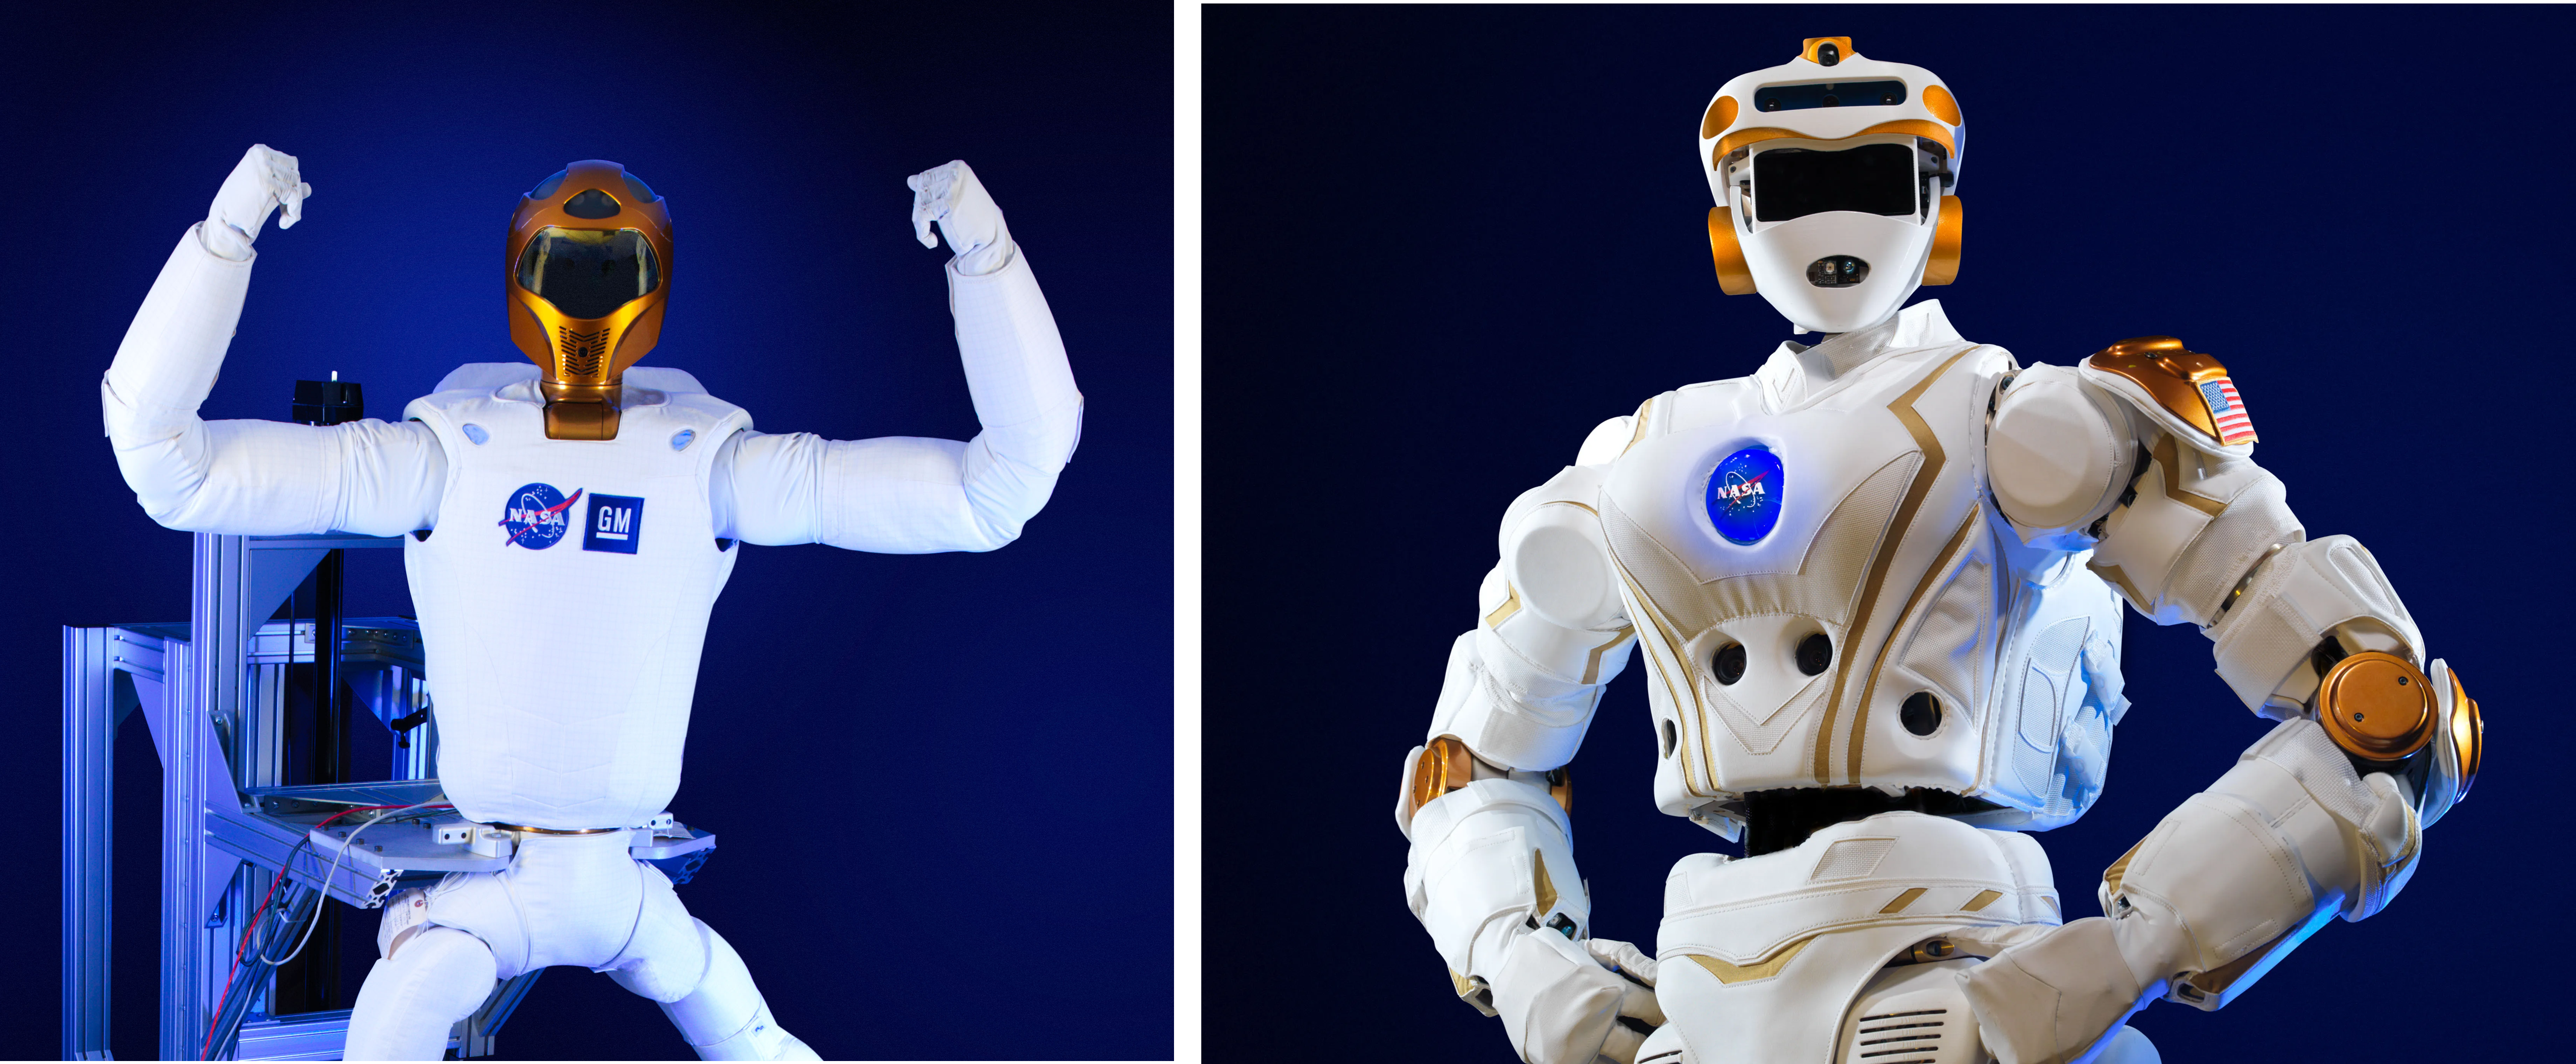
Pictures of two humanoid robots are displayed side-by-side.
NASA’s Robonaut 2 (left) and Valkyrie humanoid robots.
NASA

Today the team supports a variety of agency projects and programs, some of which are exploring connections to building the Moon Base, humanity’s first lunar outpost. “Our work is a combination of technology research and development, and applied technology on the operational side,” Azimi said. The team also collaborates with private industry and other external partners that face similar challenges in their work, such as an oil and gas company seeking to leverage robotic technologies in harsh environments and for riskier tasks.

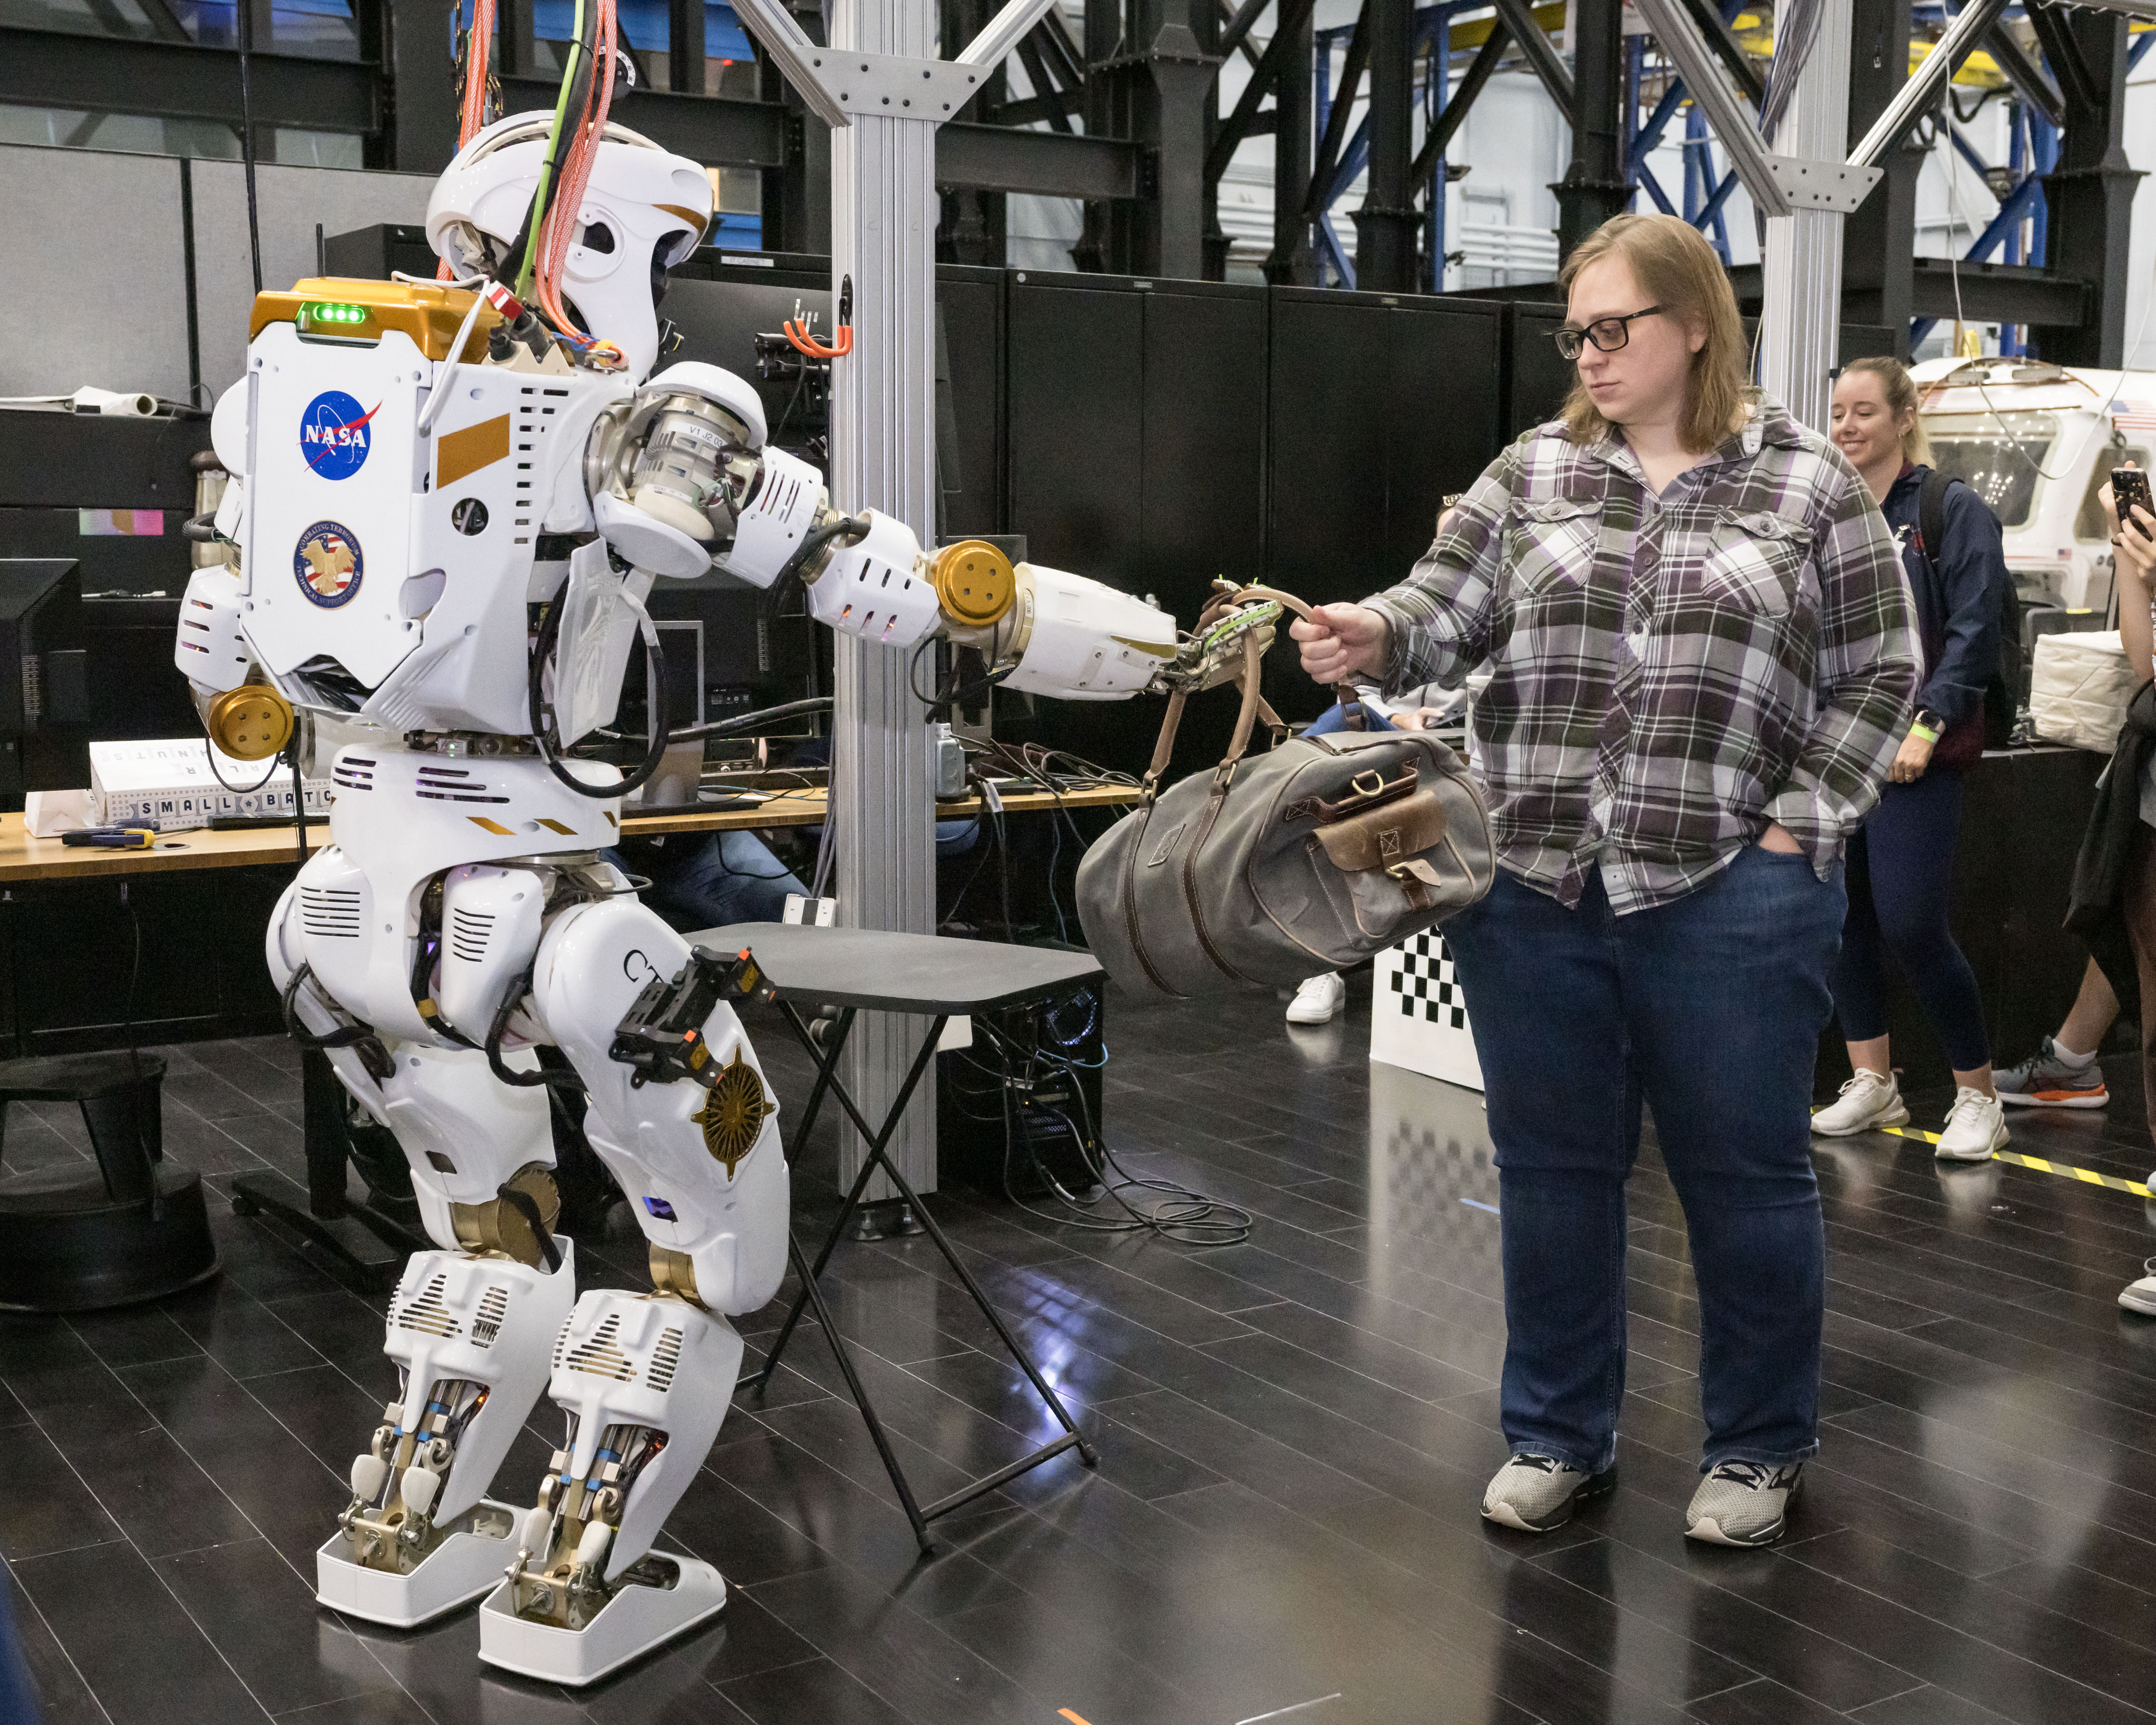
A humanoid robot hands a duffel bag to a woman wearing casual clothes.
During a demonstration, Valkyrie hands Dexterous Robotics Team member Emily Sheetz a packed duffel bag.
NASA/Helen Arase Vargas

A major focus for the team has been development of the Integrated Mobile Evaluation Testbed for Robotics Operations (iMETRO) facility at Johnson. Available to NASA programs and external partners, iMETRO is designed to support the adaptation of terrestrial robotic technologies for human-supervised space exploration applications such as logistics, maintenance, and scientific research. The facility comprises open-source software and simulation assets, as well as space vehicle and habitat mockups, a selection of “house robots,” and an outdoor rock yard. Offering digital and physical facilities gives iMETRO users the flexibility to test a whole robot or a single hardware or software component.

Azimi said iMETRO helps remove the guesswork from NASA’s collaboration with external partners. “It shows them the things we actually need done so they don’t have to speculate,” he said. “We can also bring together the people who are developing the robotic technologies – hardware, software, or both – with the people who are actually designing a lunar surface habitat or rover.” This enables different teams to learn from each other: The technology providers gain a better understanding of the habitat, while the habitat designers learn what features are needed to accommodate a robot. “They can learn about how robots perceive the world and interact with objects, and what is difficult for a robot compared to a human,” Azimi said. “It’s not necessarily a totally different interface, and something like a bigger handle or better lighting might make things easier for a person as well.”

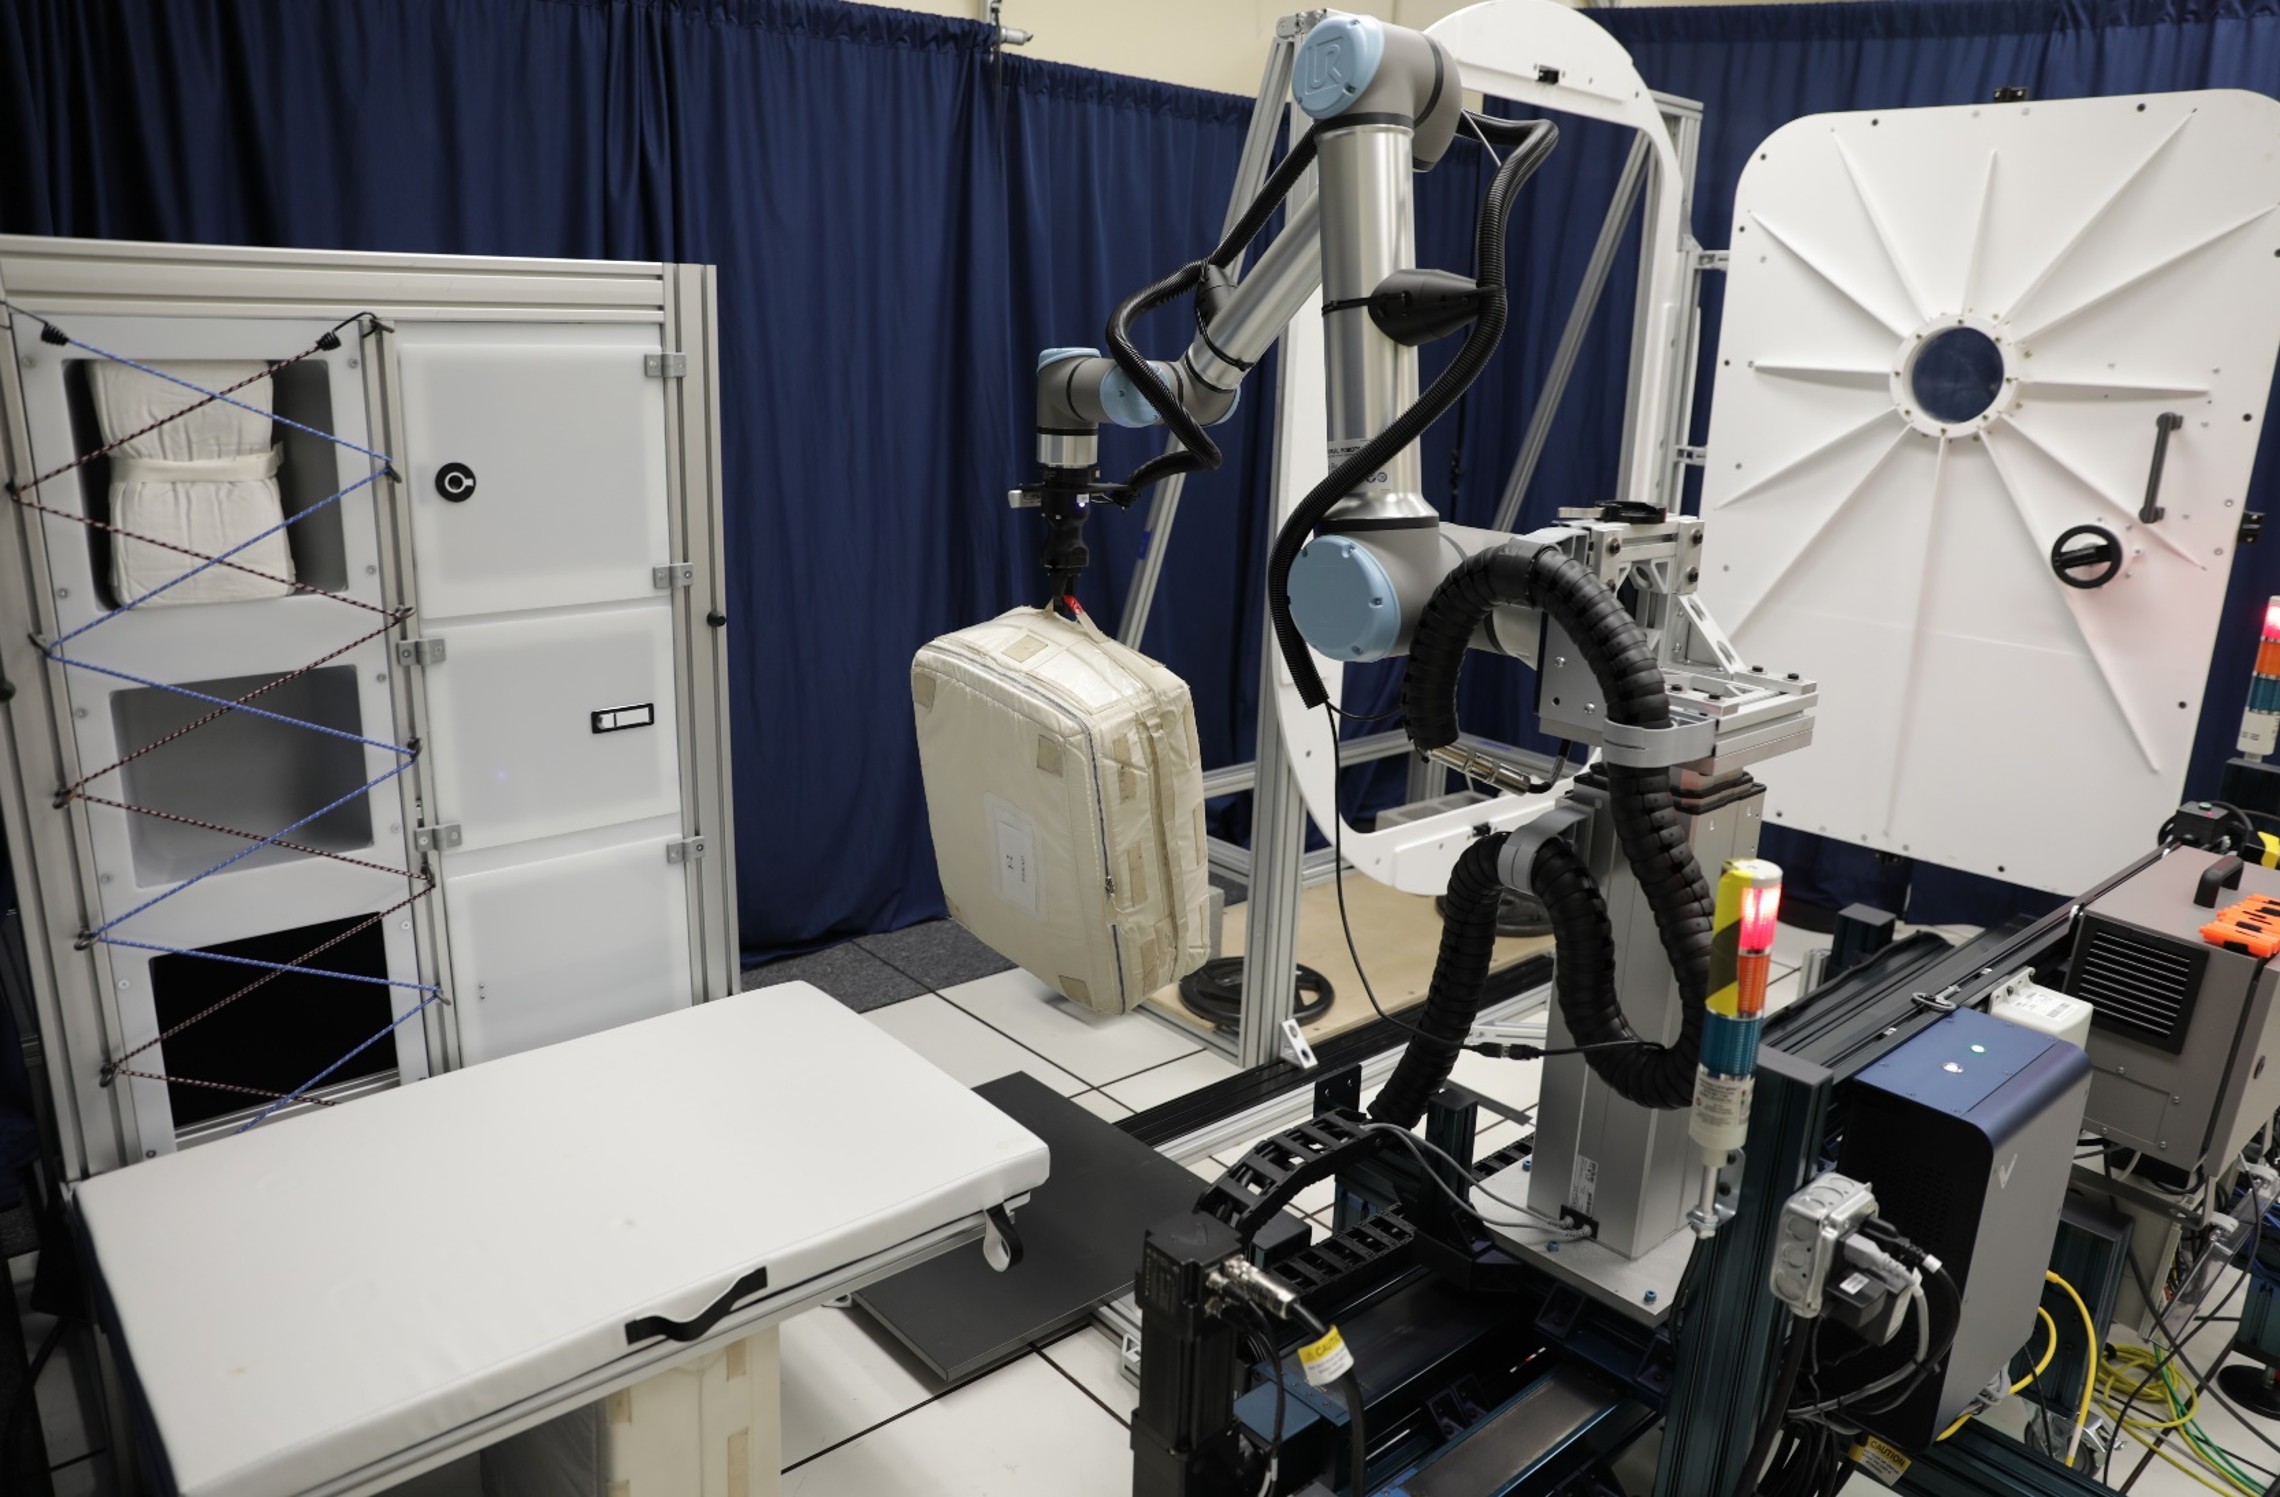
In one case, a team from PickNik Inc. used iMETRO to test software enabling a robotic arm to recognize a spacecraft hatch, then turn the latch, grasp the handle, and open the door. The arm was then able to transfer cargo bags between the hatch and a bin. The facility also supported a NASA intern’s development and testing of software that used a common commercial robotic arm and camera to inspect and maintain a cold stowage freezer like those aboard the space station.  

Robotic system components are shown in a lab setting, with blue drapery in the background.
Components of the Dexterous Robotics Team’s iMETRO facility.
NASA

Azimi acknowledged the team’s near-term emphasis on technologies that can support a sustained human presence on the lunar surface but noted those technologies also have applications for future missions to Mars. In fact, the team is collaborating with other agency organizations on a forthcoming NASA challenge that will invite the public to share their ideas for technology solutions for Mars exploration.

Azimi said he is often asked why there is a robotics team at Johnson. “It’s really about the human elements – either working in environments designed for humans or working alongside humans. That’s our niche,” he said. “We’re uniquely positioned to bring in folks who are designing the human environments.”

Powered by WPeMatico

Get The Details…
Linda E. Grimm
Uncovering the Valleys Hidden Below Greenland’s Ice

Uncovering the Valleys Hidden Below Greenland’s Ice

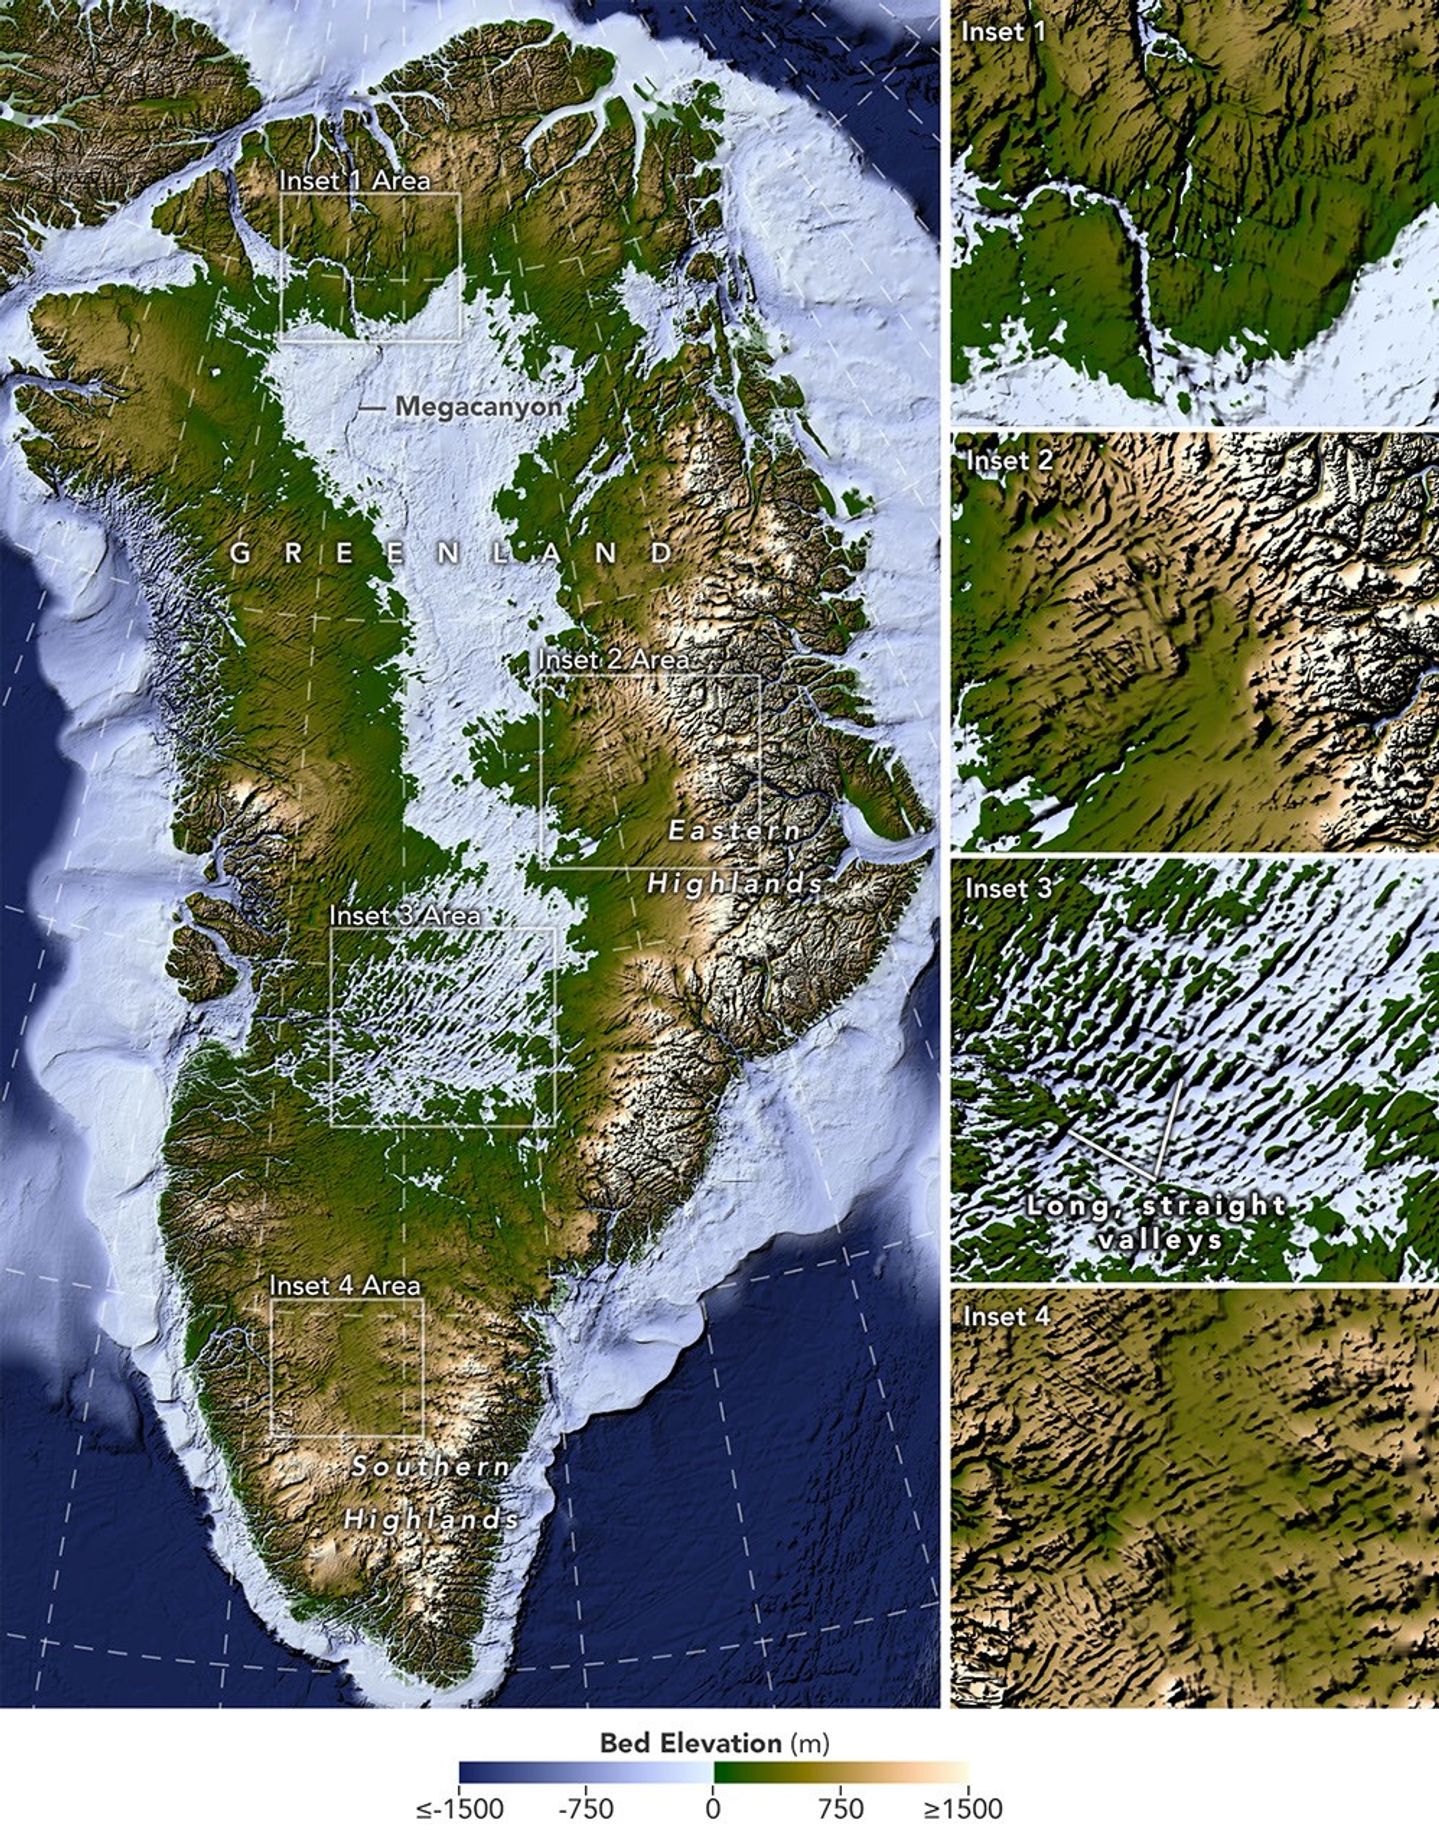
A large map on the left shows Greenland’s bedrock topography that lies below the ice sheet. A column of smaller maps on the right zooms in on several features, including long, straight valleys on the west-central part of the island. Other insets show a megacanyon, as well as valleys radiating outward from the highlands.
A newly developed method for mapping the bedrock beneath Greenland’s ice sheet reveals the island’s hidden topography. Among the most striking finds are long, straight valleys in the west-central region, some mapped for the first time and others extending farther inland than previously known (inset 3).
NASA Earth Observatory/Lauren Dauphin, based on data from Chartrand et al.

Greenland is capped with a vast ice sheet that spans 1.7 million square kilometers (656,000 square miles) and measures more than 3 kilometers (1.9 miles) at its thickest point. Below all this ice lies a landscape human eyes have never seen directly. But a newly developed method for mapping this hidden bedrock has produced the most detailed and accurate view of it yet.

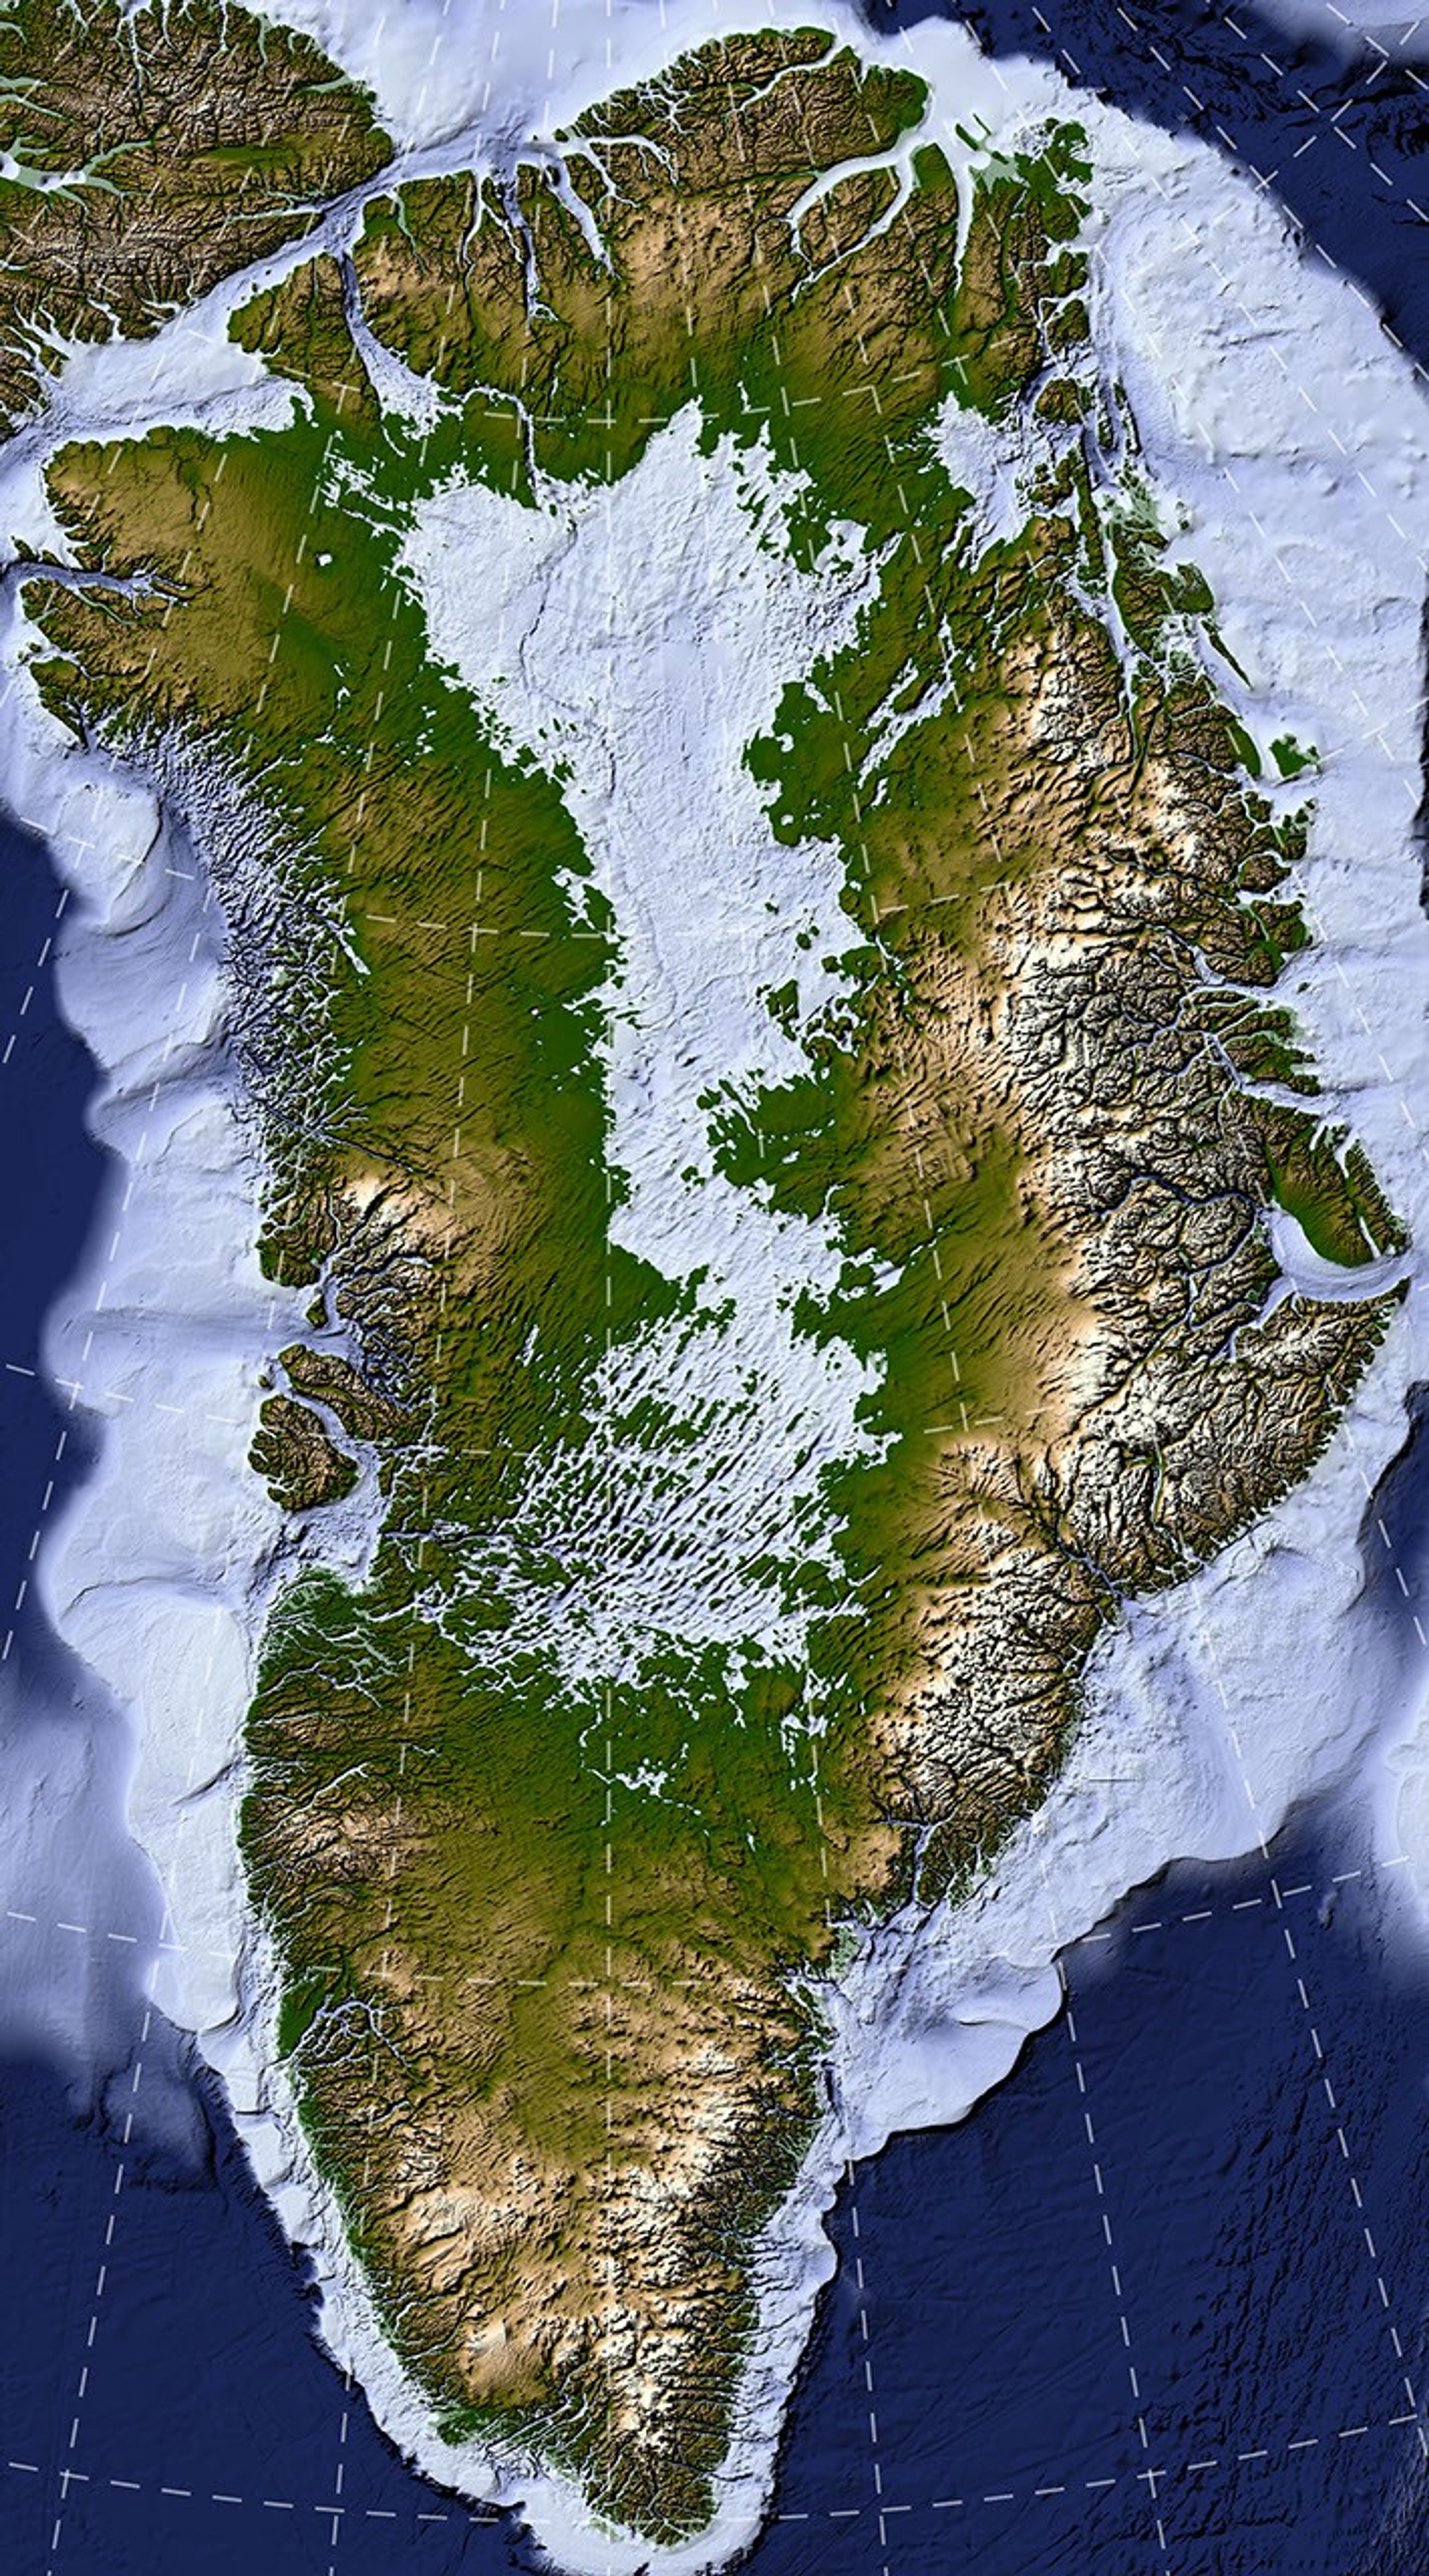
The new map reveals an expansive network of valleys carved into the surface beneath the Greenland Ice Sheet. Many of the features formed well before most of the ice above them existed, offering new context for the island’s geologic history—and potentially helping scientists refine projections of the ice sheet’s future. Scientists described the newly mapped valleys in a NASA-led paper published in Geophysical Research Letters.

The map, shown above, was derived from a method called Ice Flow Perturbation Analysis. As ice flows over a valley or ridge, the topography leaves a faint signature on the ice surface. Satellites map the ice surface in fine detail, and scientists can use these subtle bumps and dips to infer the shape of the landscape buried below. The work aims to improve future versions of BedMachine Greenland, a high-resolution dataset of the terrain beneath the ice sheet.

Using the technique, researchers manually mapped 1,943 subglacial valleys beneath the Greenland Ice Sheet, about a third of which are newly identified. About half of the valleys included in BedMachine Greenland, primarily near the ice sheet’s edge, are now known to extend farther inland than that map indicates, in some cases by hundreds of kilometers.

Some aspects of the new map align with the current understanding of how Greenland’s landscapes formed. For instance, many of the valleys appear to begin in the southern and eastern highlands, where the ice sheet is thought to have first formed. Near the eastern highlands, the map reveals a mountain range beneath the ice, with interconnected valleys and relief that increases toward the coast. These alpine-style landforms may have survived under the ice since at least the Pliocene.

Other aspects of the topography are more puzzling. The analysis indicates numerous valleys, especially in the west-central region, that are long, straight, and consistently aligned in a southwest-northeast direction. This orientation suggests a tectonic influence, generating preferential pathways along which water could flow and valleys could form. “That’s a riddle to us,” said Joe MacGregor, a NASA cryospheric scientist and co-author of the study. “Greenland is justifiably usually treated as a rigid block of old rock that is simply translated as needed to accommodate the motion and interactions of other tectonic plates.”

Separately, the angles at which the valleys branch offer another insight into their origin. Their relatively wide branching angles suggest that surface water didn’t act alone; instead, a widespread groundwater network—seeping upward and eroding the surrounding rock—likely helped carve the valleys before the ice sheet formed.

Mapping these valleys matters for understanding the ice sheet, which has continued to dramatically reshape the landscape. Ice flow concentrates in valleys, where it forms glaciers that eventually calve into fjords at the periphery of the ice sheet. This creates a reinforcing cycle: ice funneling through a valley gets thicker, thicker ice flows faster, and faster flow carves the valley even deeper.

This carving power is especially evident along western Greenland. MacGregor likened it to the glacially incised landscape at Yosemite, with Greenland’s western coast resembling, as he put it, “El Capitan after El Capitan.”

Studying the valleys also matters for the ice sheet’s future. Because the relationship between ice flow and valleys is well understood, scientists expect that as the ice sheet retreats, flow will continue to concentrate wherever the valleys already are. “The better we understand the topography now,” MacGregor said, “the better sense we’ll have of what it will look like in the longer term—beyond the next decade or two—as faster ice flow propagates into Greenland’s interior.”

NASA Earth Observatory map by Lauren Dauphin using data from Chartrand et al. Story by Kathryn Hansen.

References & Resources

You may also be interested in:

Stay up-to-date with the latest content from NASA as we explore the universe and discover more about our home planet.

An Uncommon Drifter in the Denmark Strait

4 min read

A large iceberg, observed in summer 2026, had drifted more than 1,000 kilometers south from the northeastern Greenland bay where…

Article

A Bare Summer for Barnes Ice Cap

4 min read

The expanse of glacial ice on Canada’s Baffin Island lost its snow cover quickly and early in summer 2026, revealing…

Article

Pasterze Hangs on as Austria’s Largest Glacier

4 min read

One narrowing icefall remains the linchpin for the Alpine glacier—and it may not be long for this world.

Article

Powered by WPeMatico

Get The Details…

APOD: 2026 September 27 – Andromeda Before and After Photoshop

APOD: 2026 September 27 – Andromeda Before and After Photoshop

APOD

Astronomy Picture of the Day

Discover the cosmos! Each day a different image or photograph of our fascinating universe is featured, along with a brief explanation written by a professional astronomer.

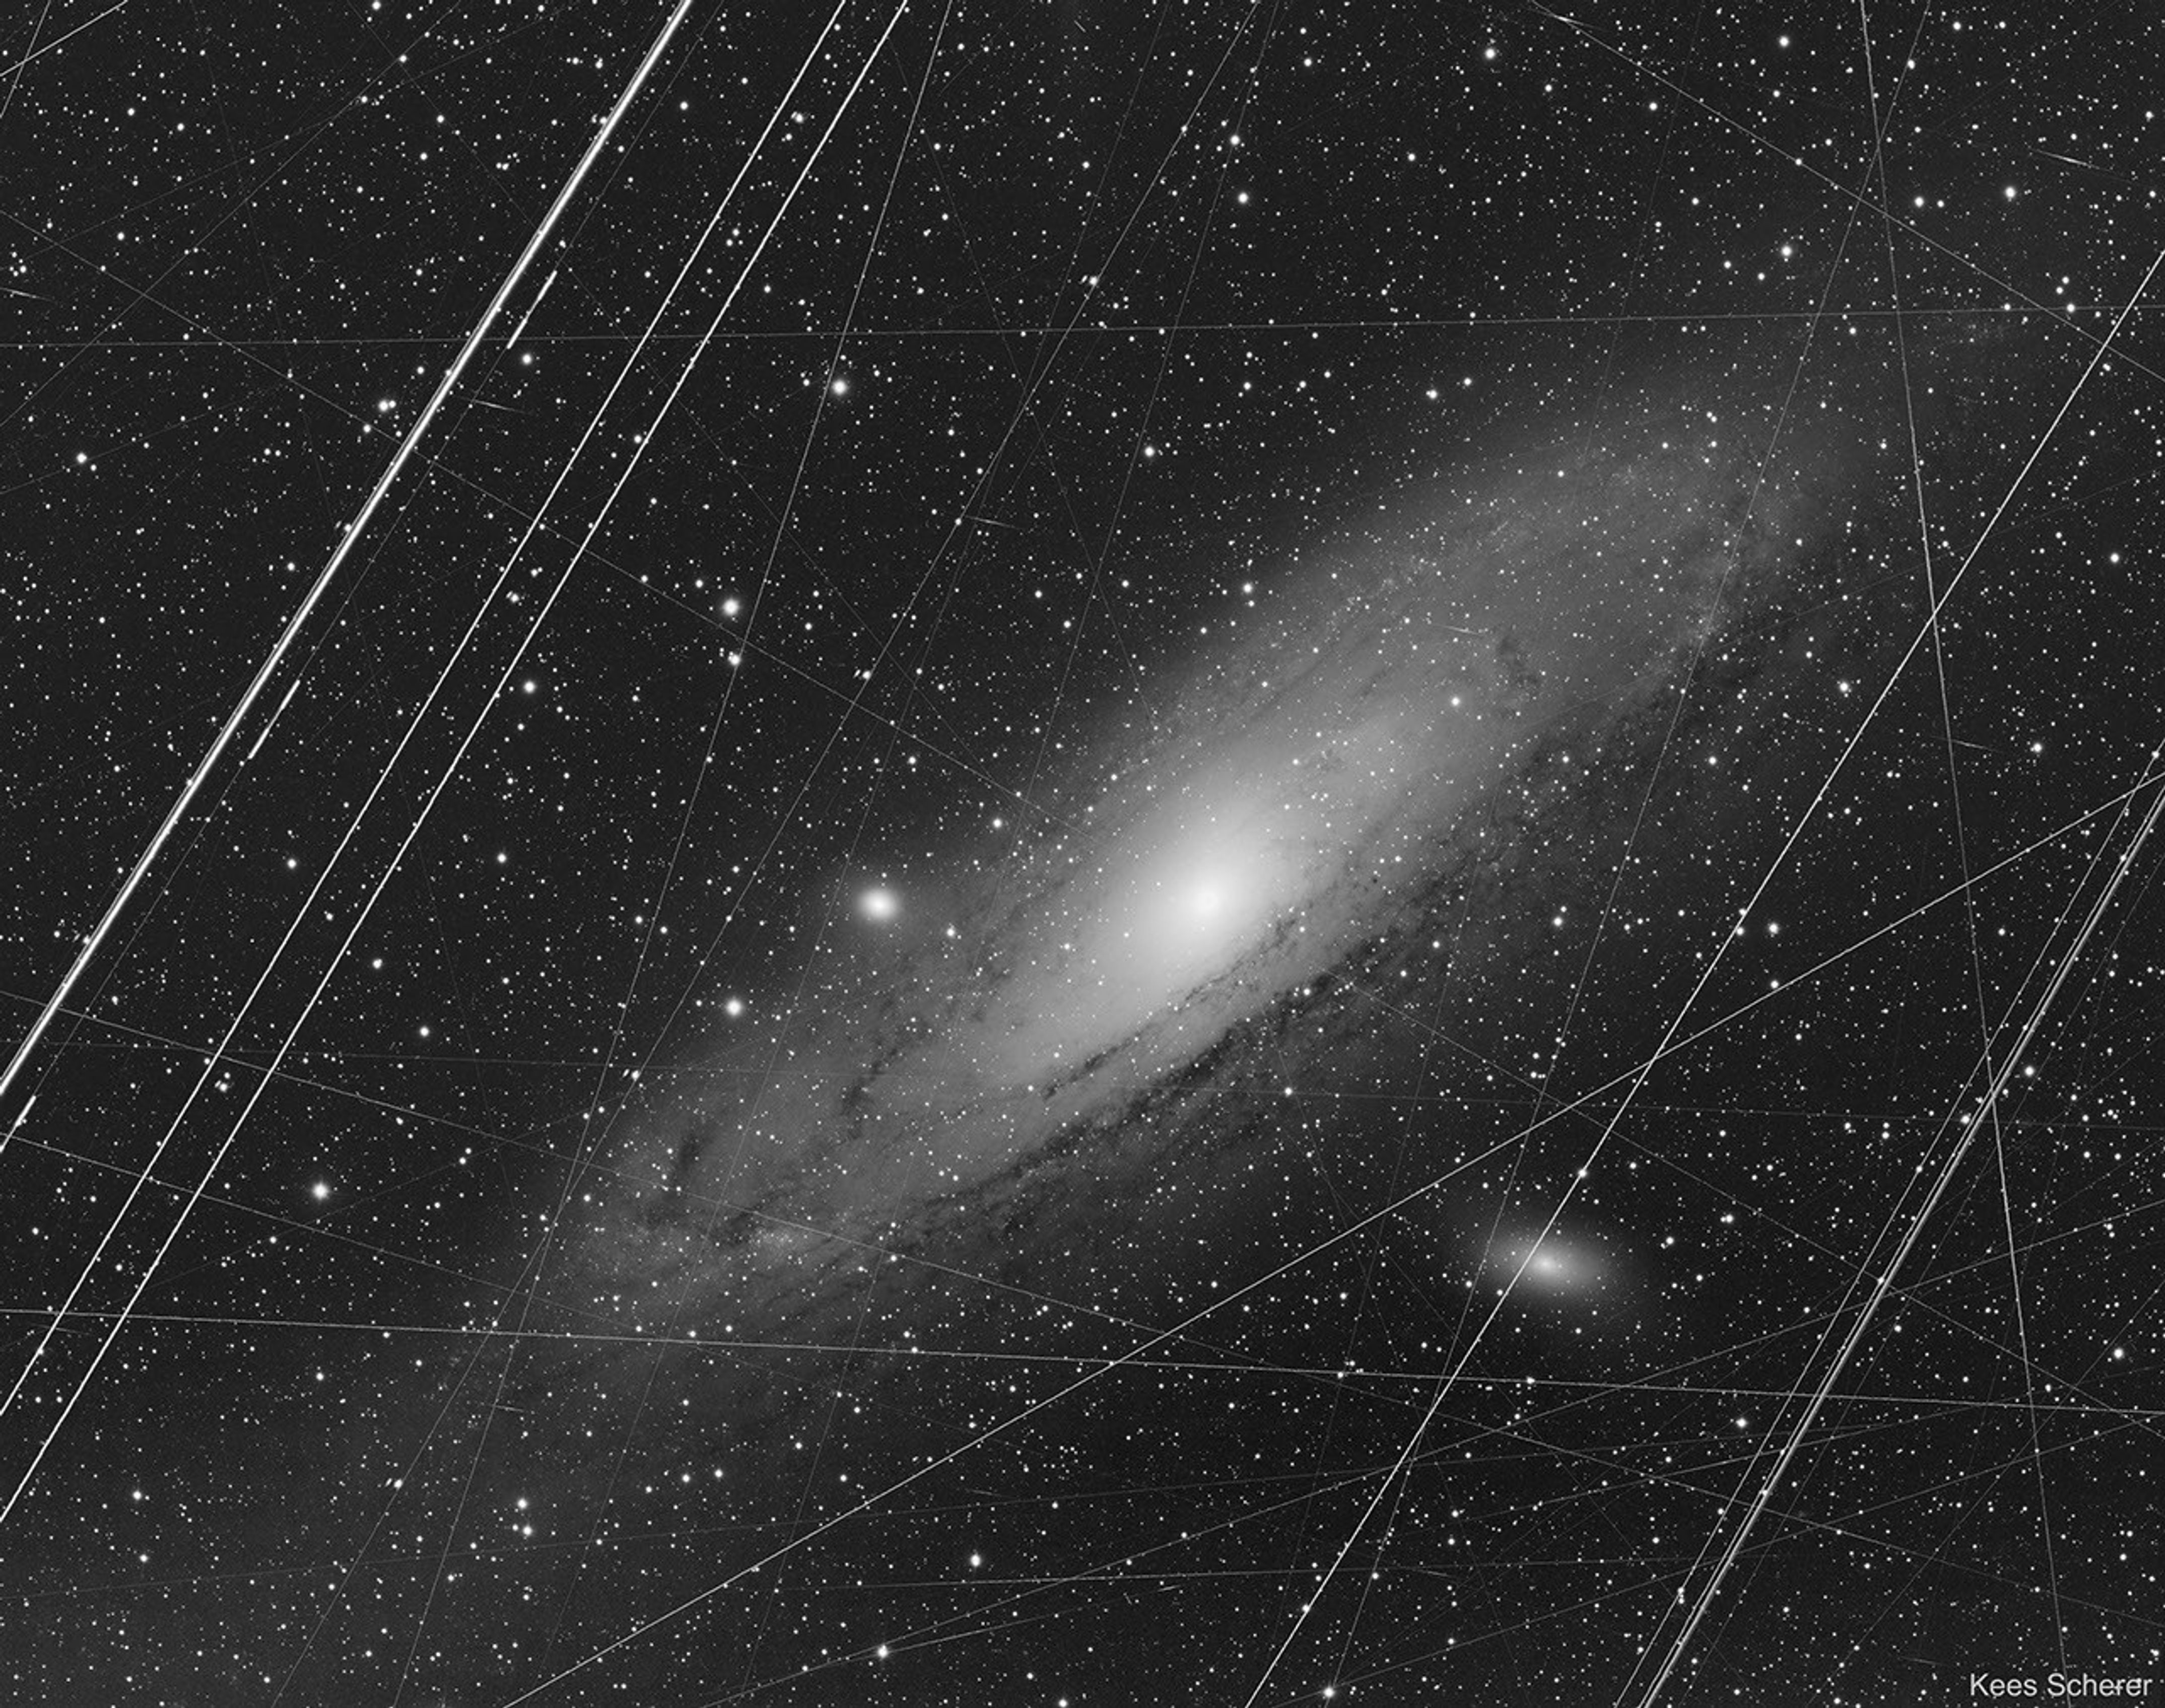
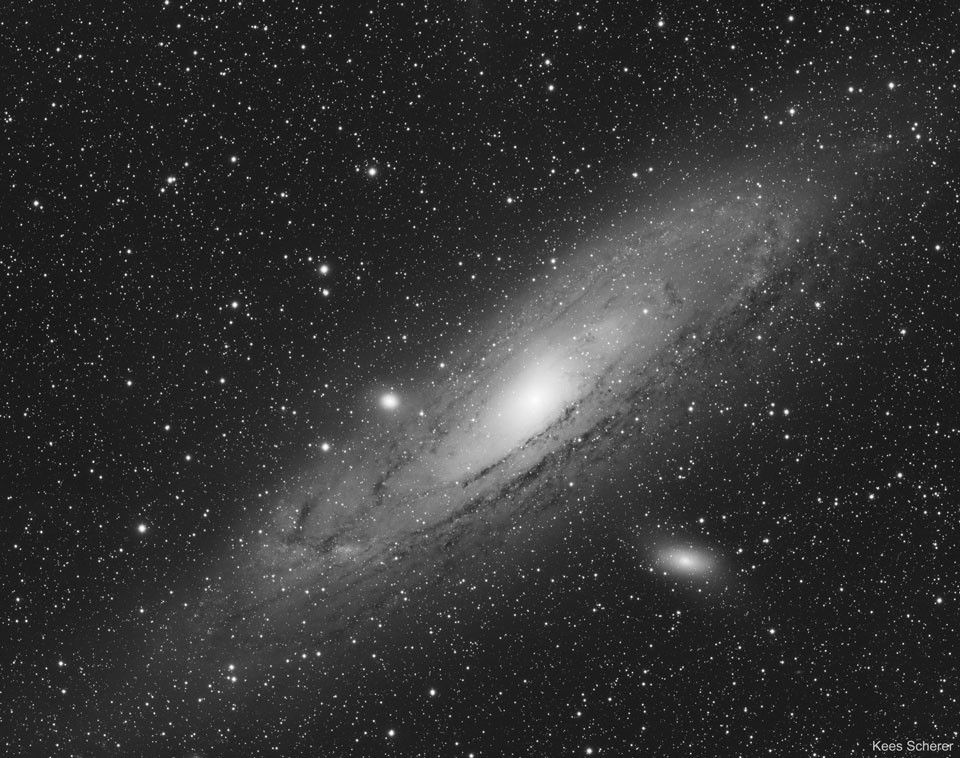
Before image of the Andromeda galaxy with streaks marring the field of view.Image of the Andromeda Galaxy after processing out blemishes.

Andromeda Before and After Photoshop

Explanation: What does the Andromeda galaxy really look like? The featured before image shows how our Milky Way Galaxy‘s closest major galactic neighbor really appears in a long exposure through Earth‘s busy skies and with a digital camera that introduces normal imperfections. The picture is a stack of 223 images, each a 300 second exposure, taken from a garden observatory in Portugal during 2019. Obvious image deficiencies include bright parallel airplane trails, long and continuous satellite trails, short cosmic ray streaks, and bad pixels. In the after image, these imperfections were actually not removed with Photoshop specifically, but rather greatly reduced with a series of computer software packages that included Astro Pixel Processor, DeepSkyStacker, and PixInsight. All of this work was done not to deceive you with a digital fantasy that has little to do with the real likeness of the Andromeda galaxy (M31), but to minimize Earthly artifacts that have nothing to do with the distant galaxy and so better recreate what M31 really does look like.

APOD’s email for image submissions has changed. Please see: APOD Submissions
APOD’s main NASA site is moving: From apod.nasa.gov to science.nasa.gov/apod
Tomorrow’s picture: cosmic latte

Date September 26, 2026
Credit & Copyright: Kees Scherer
Authors & editors: Robert Nemiroff, Jerry Bonnell, Cecilia Chirenti, Keighley Rockcliffe
A service of: ASD at NASA / GSFC,
NASA Science Activation & Michigan Tech. U.

Powered by WPeMatico

Get The Details…

APOD: 2026 September 26 – Mirrored Meteor and Milky Way

APOD: 2026 September 26 – Mirrored Meteor and Milky Way

APOD

Astronomy Picture of the Day

Discover the cosmos! Each day a different image or photograph of our fascinating universe is featured, along with a brief explanation written by a professional astronomer.

A large, segmented telescope mirror is seen against the night sky along with  the Milky Way and a bright meteor.

Mirrored Meteor and Milky Way

Explanation: On August 15, this perseid meteor streaked through night skies over the Observatorio del Roque de los Muchachos at La Palma, Canary Islands, Spain. The bright and colorful meteor trail was captured next to the central Milky Way, whose dark interstellar dust clouds and luminous starlight reach above the horizon. In the foreground of this tantalizing celestial scene is the 23 meter diameter mirror of the prototype Large-Sized Telescope (LST-1). LST-1 is the first telescope constructed at the northern hemisphere site of the innovative Cherenkov Telescope Array Observatory. With 198 hexagonal mirror segments and a large, high-efficiency, pixelized camera, LST-1 is designed to detect extremely brief, atmospheric visible light flashes. Lasting about a billionth of a second, the visible light flashes are triggered by energetic gamma-rays from cosmic sources such as distant active galaxies and gamma-ray bursts. Of course, on that night some individual mirror segments of LST-1 also reflected the atmospheric flash of the bright perseid meteor.

APOD’s email for image submissions has changed. Please see: APOD Submissions.
APOD’s main NASA site is moving: From apod.nasa.gov to science.nasa.gov/apod
Tomorrow’s picture: before and after

Date September 26, 2026
Credit & Copyright: Jeff Dai (TWAN)
Authors & editors: Jerry Bonnell, Cecilia Chirenti, Robert Nemiroff, Keighley Rockcliffe
A service of: ASD at NASA / GSFC,
NASA Science Activation & Michigan Tech. U.

Powered by WPeMatico

Get The Details…