

NASA, ESA to Discuss Mars Sample Return Mission
NASA will host a media teleconference at 11 a.m. EDT on Wednesday, July 27, to discuss the architecture for its Mars Sample Return campaign.
Powered by WPeMatico
NASA will host a media teleconference at 11 a.m. EDT on Wednesday, July 27, to discuss the architecture for its Mars Sample Return campaign.
Powered by WPeMatico
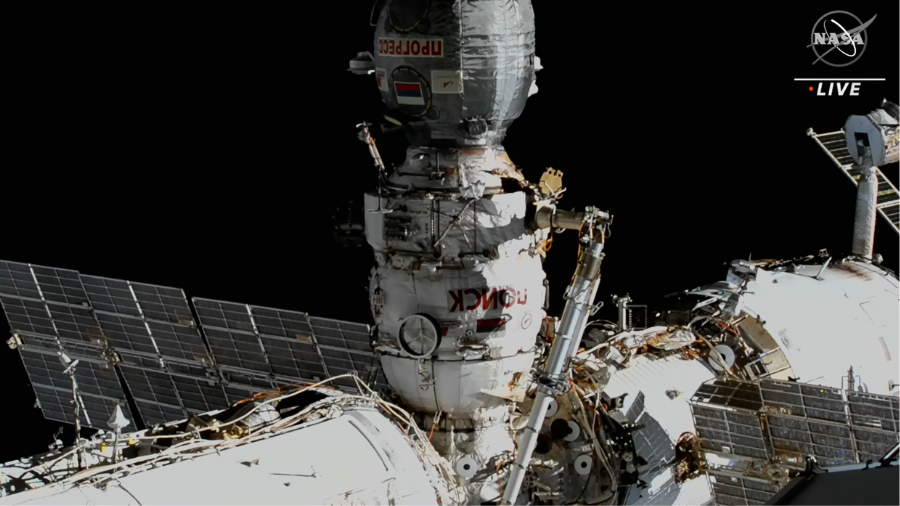
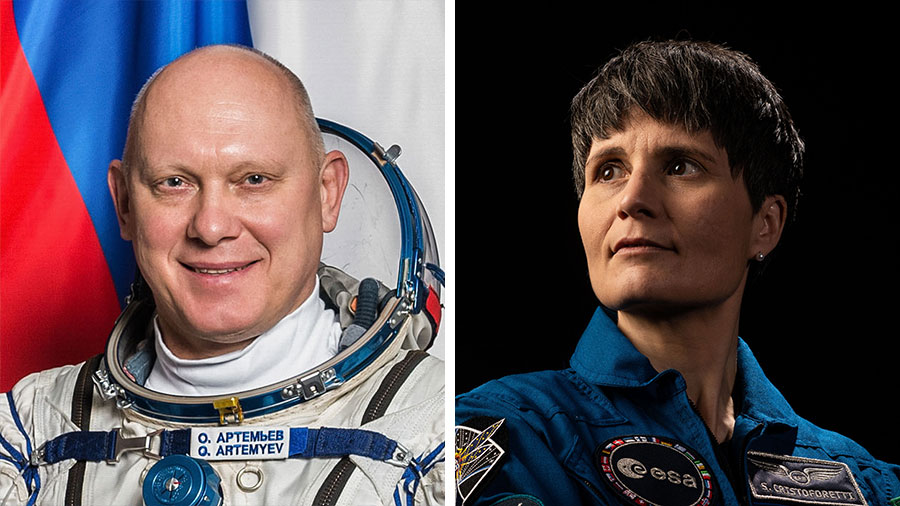
Expedition 67 Commander Oleg Artemyev of Roscosmos and Flight Engineer Samantha Cristoforetti of ESA (European Space Agency) began a spacewalk at 10:50 a.m. EDT to continue outfitting the European robotic arm on the International Space Station’s Nauka laboratory by opening the hatch of the Poisk docking compartment airlock. Coverage of the spacewalk continues on NASA Television, the NASA app, and the agency’s website.
One of the first tasks will see Artemyev and Cristoforetti deploy 10 nanosatellites designed to collect radio electronics data during the spacewalk, which will be the 251st in support of station assembly, maintenance, and upgrades.
The duo will install platforms and workstation adapter hardware near the 37-foot-long manipulator system mounted to Nauka. The spacewalkers also will relocate the arm’s external control panel, replace a protective window on the arm’s camera unit, and extend a Strela telescoping boom from Zarya to Poisk to facilitate future spacewalks.
Artemyev is wearing a Russian spacesuit with red stripes, while Cristoforetti is wearing a Russian suit with blue stripes. This will be the sixth spacewalk in Artemyev’s career, and the first for Cristoforetti. It will be the sixth spacewalk at the station in 2022 and the 251st spacewalk for space station assembly, maintenance, and upgrades.
Learn more about station activities by following the space station blog, @space_station and @ISS_Research on Twitter, as well as the ISS Facebook and ISS Instagram accounts.
Get weekly video highlights at: http://jscfeatures.jsc.nasa.gov/videoupdate/
Get the latest from NASA delivered every week. Subscribe here: www.nasa.gov/subscribe
Mark Garcia
Powered by WPeMatico
NASA Television coverage is underway of today’s spacewalk with a Russian cosmonaut and an ESA (European Space Agency) astronaut to continue outfitting the European robotic arm on the International Space Station’s Nauka laboratory. Coverage of the spacewalk is on NASA Television, the NASA app, and agency’s website.
Expedition 67 Commander Oleg Artemyev of Roscosmos and Flight Engineer Samantha Cristoforetti of ESA will install platforms and workstation adapter hardware near the European robotic arm, a 37-foot-long manipulator system mounted to the Nauka multipurpose laboratory module. The spacewalkers also will relocate the arm’s external control panel, replace a protective window on the arm’s camera unit, and extend a Strela telescoping boom from Zarya to Poisk to facilitate future spacewalks.
Artemyev and Cristoforetti will exit out of the Poisk module about 10 a.m. EDT to begin the six-and-a-half-hour excursion. Artemyev will wear a Russian spacesuit with red stripes, while Cristoforetti will wear a Russian suit with blue stripes. This will be the sixth spacewalk in Artemyev’s career, and the first for Cristoforetti. It will be the sixth spacewalk at the station in 2022 and the 251st spacewalk for space station assembly, maintenance, and upgrades.
The European robotic arm will be used to move payloads and equipment outside the Russian segment of the station, joining the Canadian-built Canadarm2 robotic arm and the Japanese arm already supporting station maintenance, operations, and research.
Learn more about station activities by following the space station blog, @space_station and @ISS_Research on Twitter, as well as the ISS Facebook and ISS Instagram accounts.
Get weekly video highlights at: http://jscfeatures.jsc.nasa.gov/videoupdate/
Get the latest from NASA delivered every week. Subscribe here: www.nasa.gov/subscribe
Mark Garcia
Powered by WPeMatico
HDV is developing the necessary systems to enable urban drone flights that travel beyond visual sight.
Powered by WPeMatico
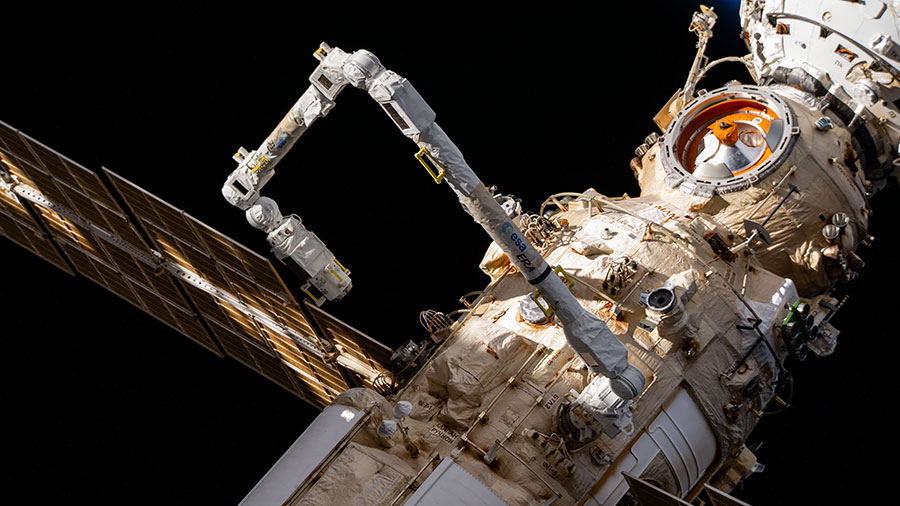
A Russian cosmonaut and an Italian astronaut are finalizing preparations for a spacewalk on Thursday to configure the International Space Station’s third and newest robotic arm. As the pair was being assisted by two cosmonauts the rest of the Expedition 67 crew ensured ongoing advanced space research was proceeding full speed ahead aboard the orbiting lab.
Station Commander Oleg Artemyev of Roscosmos and Flight Engineer Samantha Cristoforetti of ESA (European Space Agency) are scheduled to exit the space station into the vacuum of space at 10 a.m. EDT on Thursday. The spacewalkers will spend about seven hours readying the European robotic arm for operations on the station’s Russian segment. The duo will also deploy 10 nanosatellites to collect radio electronics data. NASA TV begins its live spacewalk coverage at 9:30 a.m. on the agency’s app and website.
Artemyev and Cristoforetti spent Wednesday reviewing their spacewalk procedures and checking Orlan spacesuit components. They were assisted throughout the day by cosmonauts Denis Matveev and Sergey Korsakov who will monitor the spacewalkers and help them in and out of their Orlan spacesuits on Thursday.
Science operations continued rolling ahead as the rest of the orbital residents explored space-caused accelerated aging, advanced drug development methods, and state-of-the-art optical fiber manufacturing techniques.
NASA Flight Engineers Bob Hines and Jessica Watkins took turns today exploring how microgravity affects the human immune system. Hines first set up tissue samples inside the Kibo laboratory module’s Life Science Glovebox. Afterward, Watkins examined the stem cell samples using a microscope inside the U.S. Destiny laboratory module. Watkins also spent a few moments today checking samples for the Fiber Optic Production-2 space manufacturing study.
NASA Flight Engineer Kjell Lindgren studied the mechanisms of protein crystals growing without the influence of Earth’s gravity. Observations from the Advanced Nano Step investigation may improve biochemistry research and advance the production of materials and drugs in space. Lindgren then checked on a water recycling study and stowed its hardware for return to Earth.
Learn more about station activities by following the space station blog, @space_station and @ISS_Research on Twitter, as well as the ISS Facebook and ISS Instagram accounts.
Get weekly video highlights at: http://jscfeatures.jsc.nasa.gov/videoupdate/
Get the latest from NASA delivered every week. Subscribe here: www.nasa.gov/subscribe
Mark Garcia
Powered by WPeMatico
